Haoran Yuan1,*,‡, Zekai Wang2, Boning Shao2, Haoran Lu3,*, Trevor Darrell2, Ismini Lourentzou1,†, Wei Zhan2,†
- 1University of Illinois Urbana-Champaign
- 2University of California, Berkeley
- 3Northwestern University
* Work done during a visit to UC Berkeley; ‡ Project lead; † Equal advising, co-corresponding authors
arXiv preprint arXiv:2609.24976
Citation
@article{dextacwam2026,
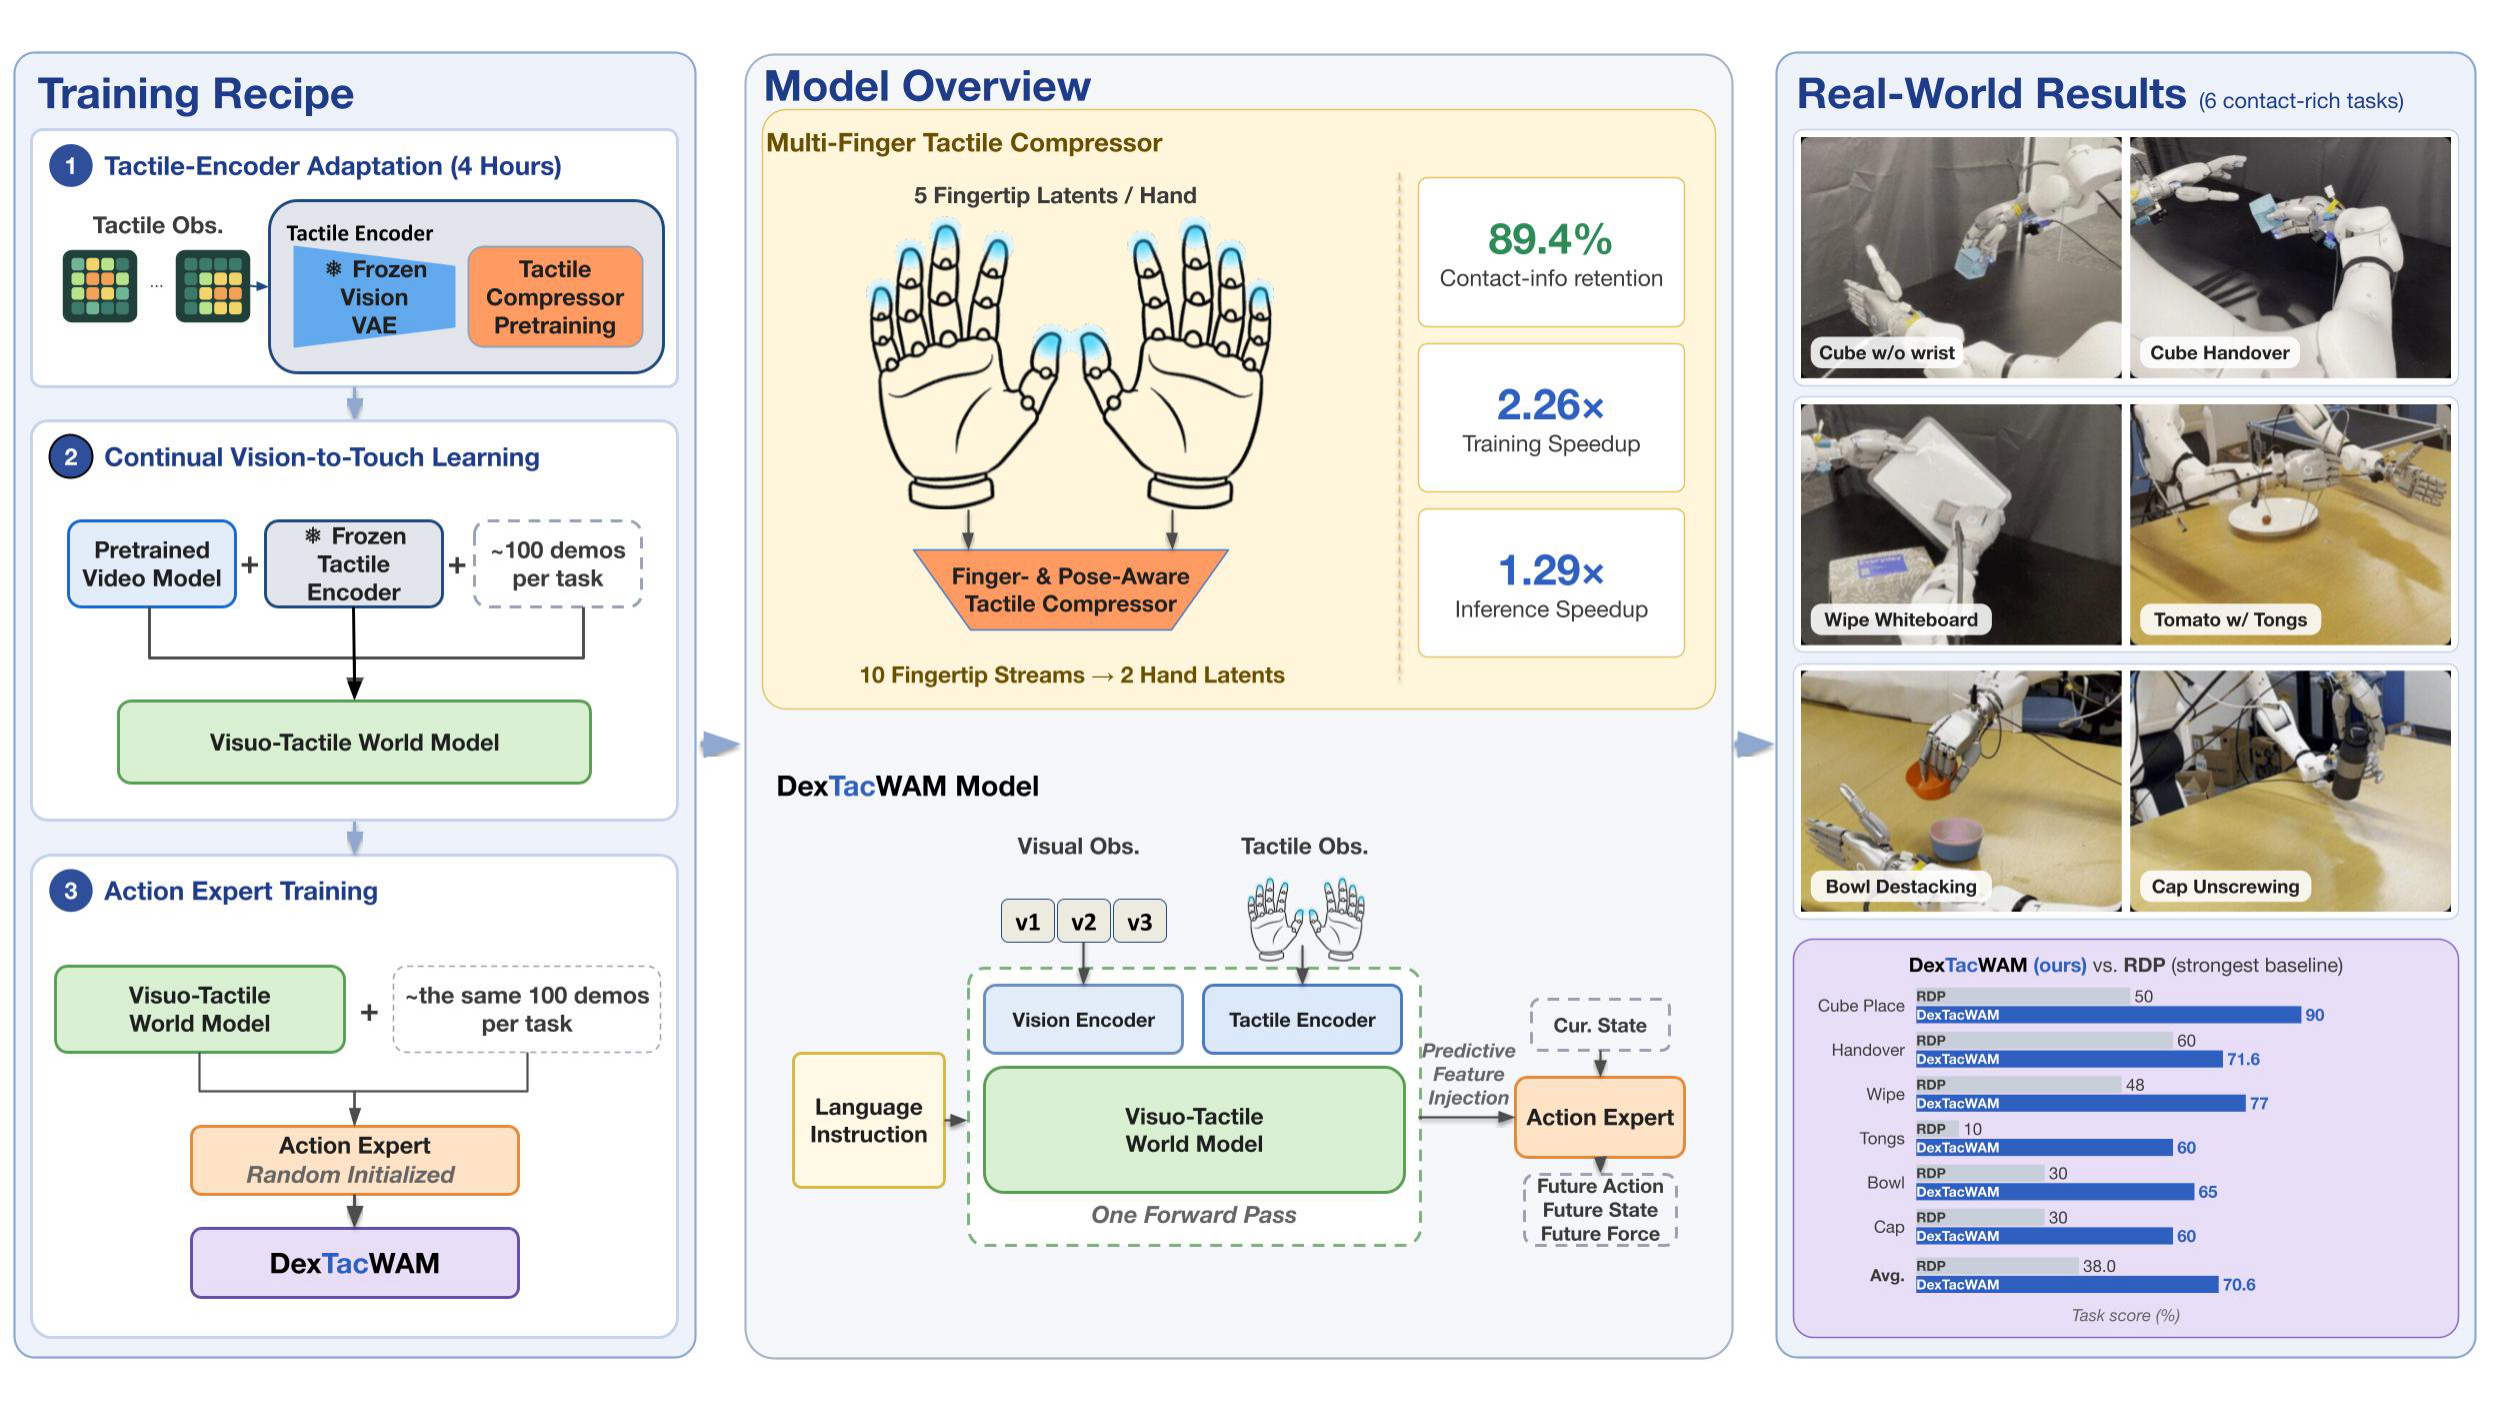
  title         = {DexTacWAM: A Visuo-Tactile World-Action Model for Dexterous Manipulation},
  author        = {Yuan, Haoran and Wang, Zekai and Shao, Boning and Lu, Haoran and Darrell, Trevor and Lourentzou, Ismini and Zhan, Wei},
  journal       = {arXiv preprint arXiv:2609.24976},
  year          = {2026}
}