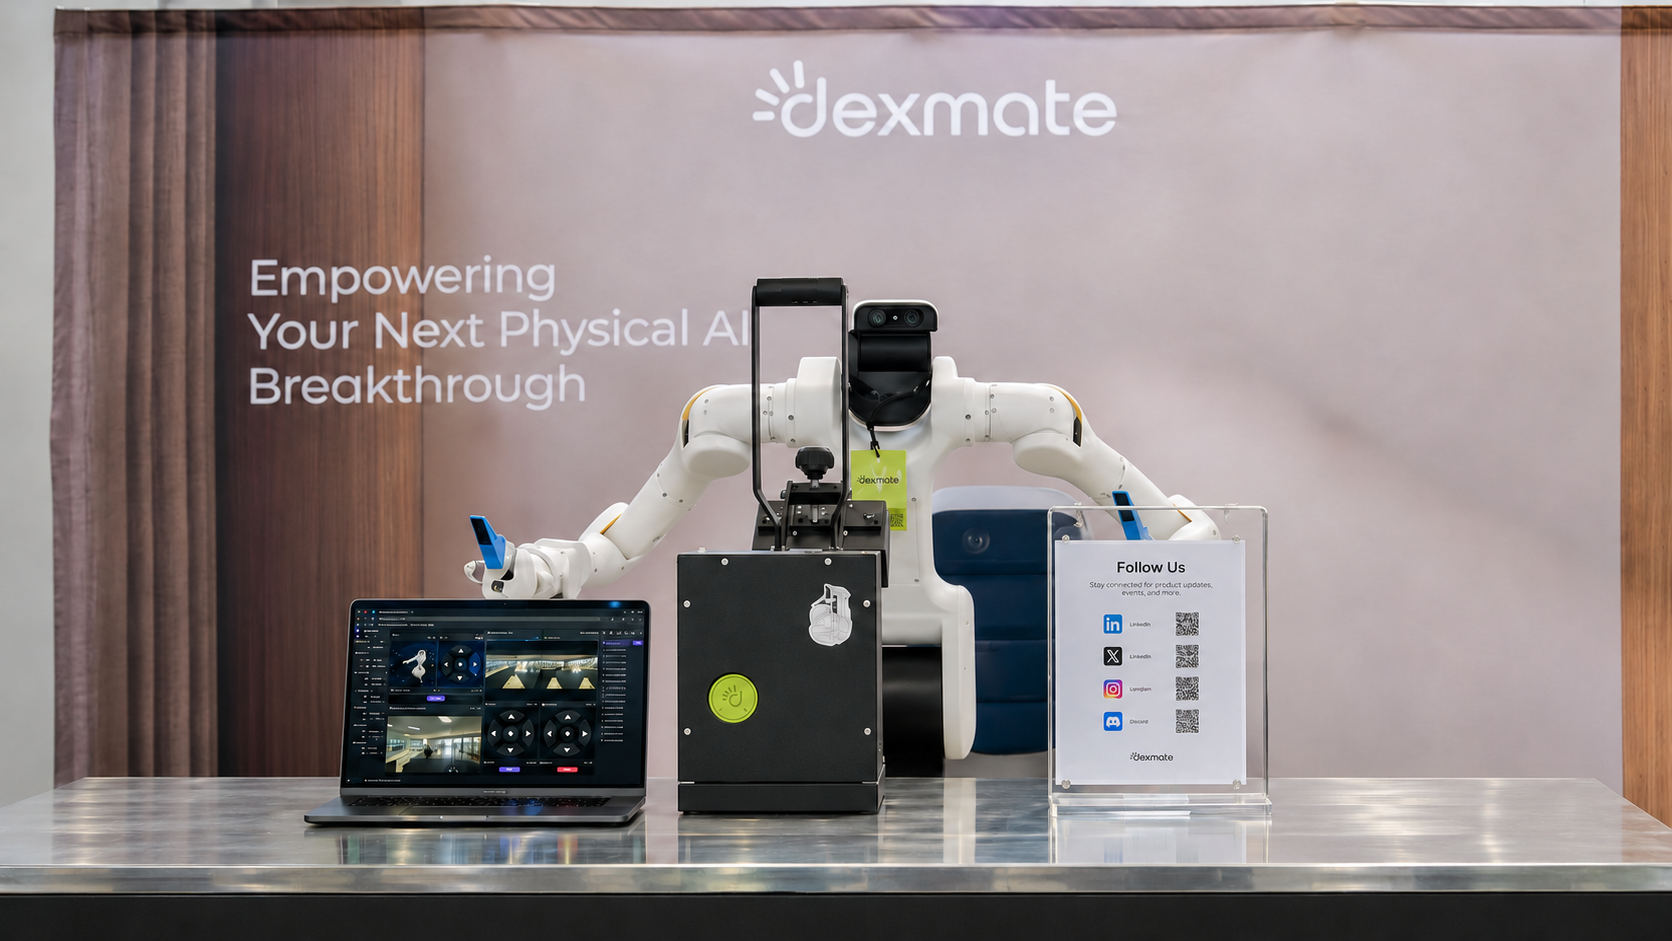
Remote Robot Teleoperation: SF-to-Fremont Control of Dexmate Vega with Foxglove
Conference attendees in San Francisco viewed live camera feeds and controlled a Vega at Dexmate’s Fremont office through a Foxglove dashboard, across separate networks.
Notes on Physical AI
Conference attendees in San Francisco viewed live camera feeds and controlled a Vega at Dexmate’s Fremont office through a Foxglove dashboard, across separate networks.
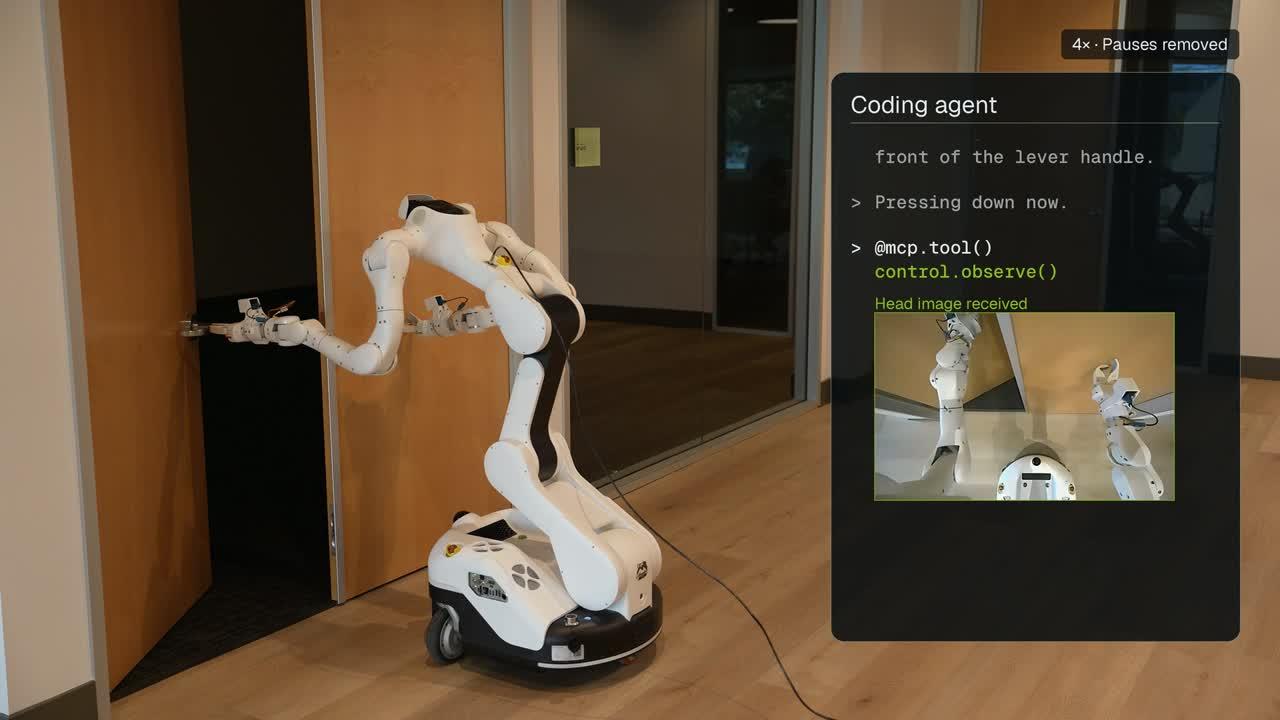
We gave Codex and Claude Code control of a Vega 1 Pro and recorded what happened between the task description and the result: what the agents build, where their time goes, and where they still fall short.
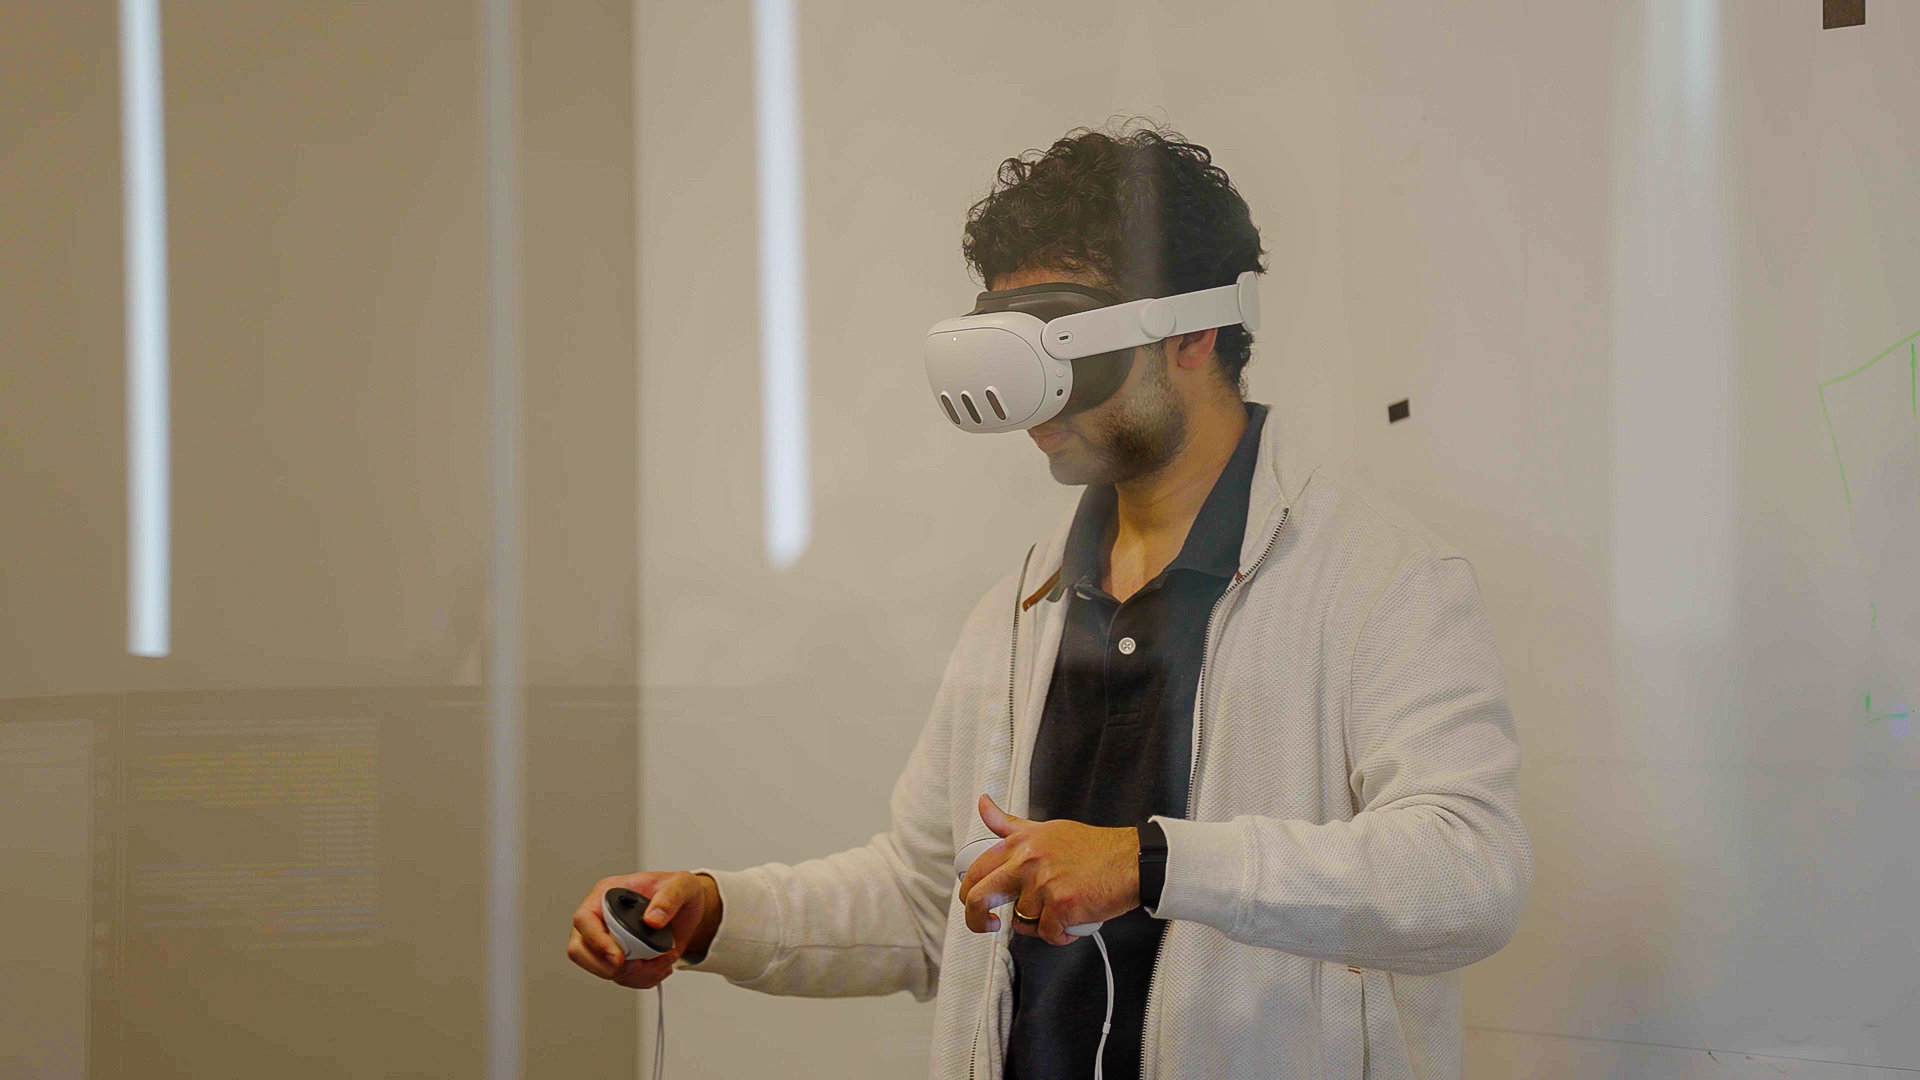
How Dexmate robot and Omniteleop help you collect teleoperation data for physical AI model training
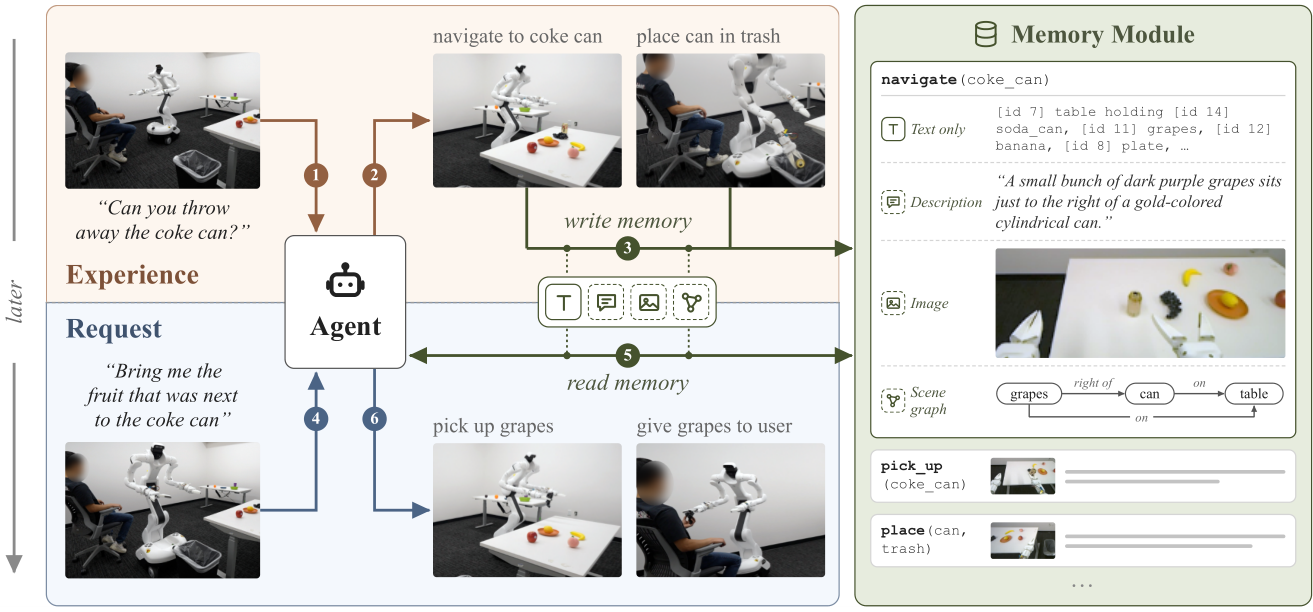
A new benchmark from Dexmate and Carnegie Mellon asks which kind of memory a robot agent should keep, and finds that saving the camera frame beats describing it.
What Industrial Physical AI actually requires, and why most robots aren’t ready.