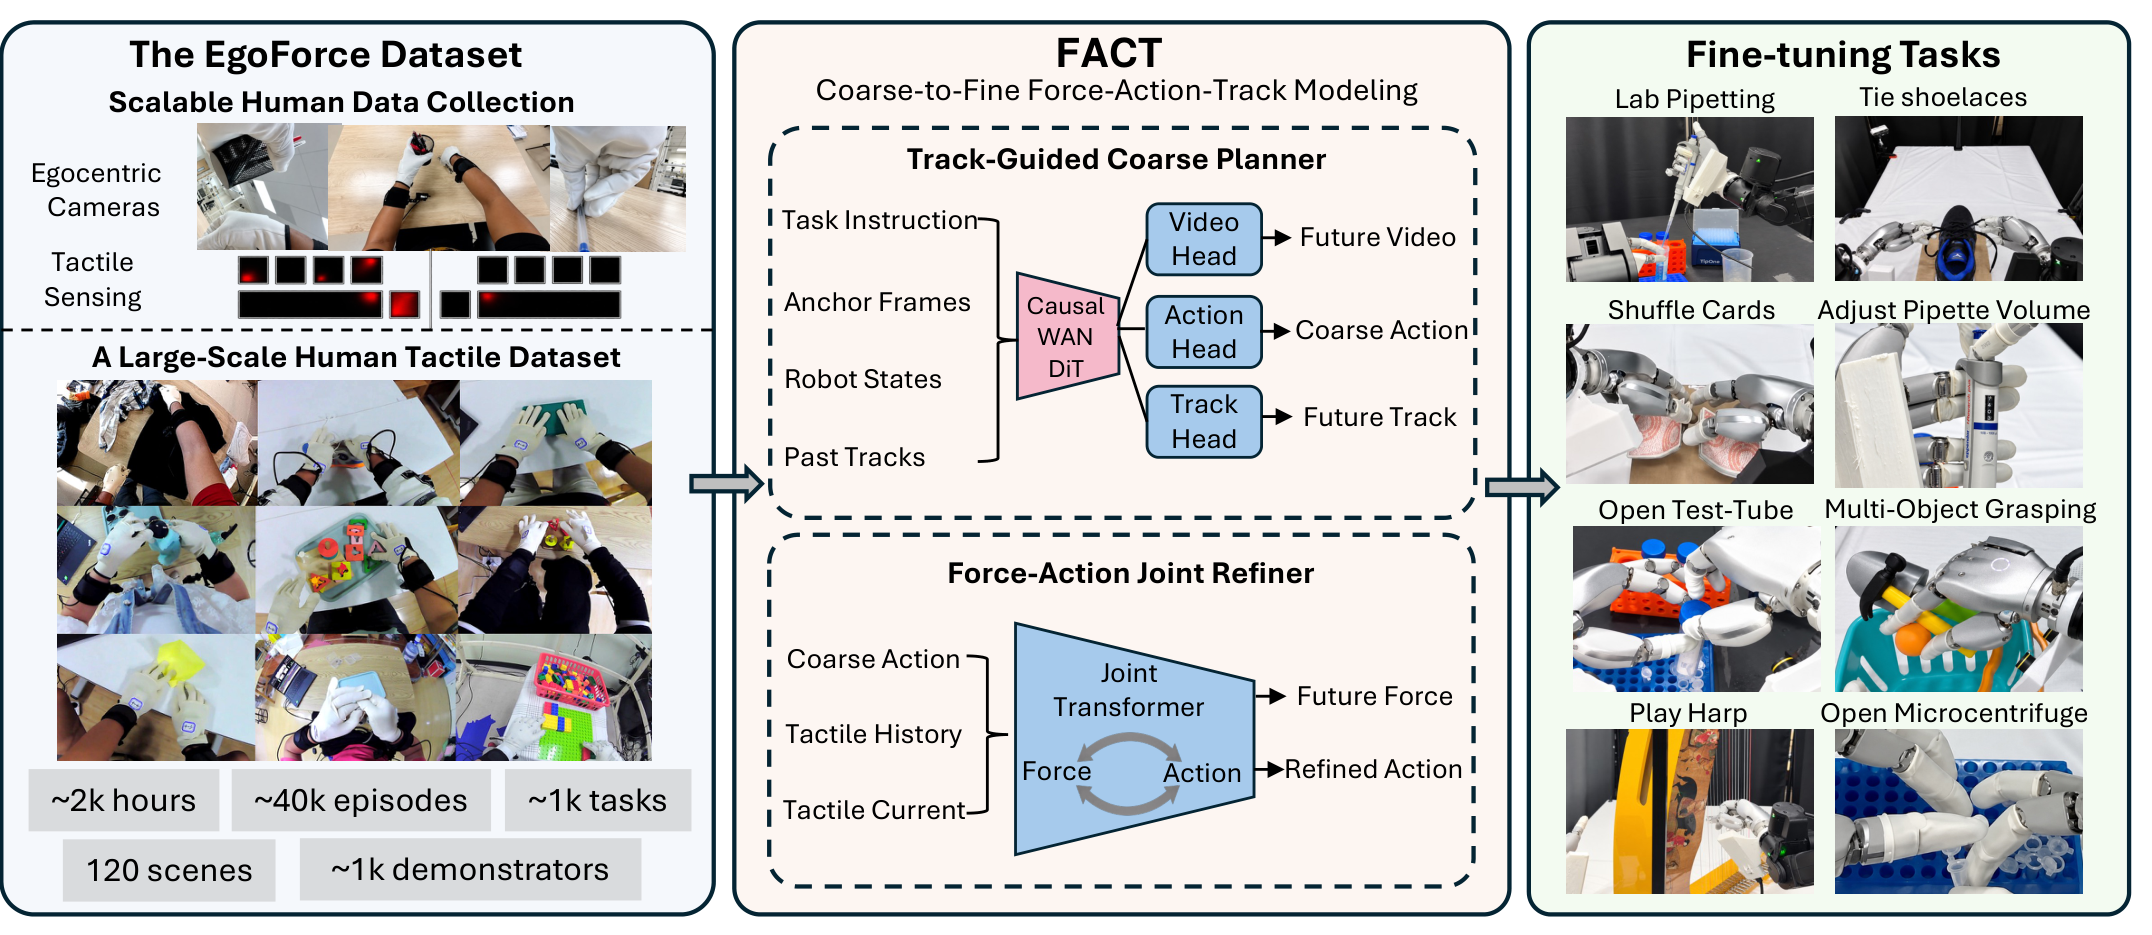
FACT: A Multimodal Force-Action-Track Foundation Model for Human-to-Robot Dexterity
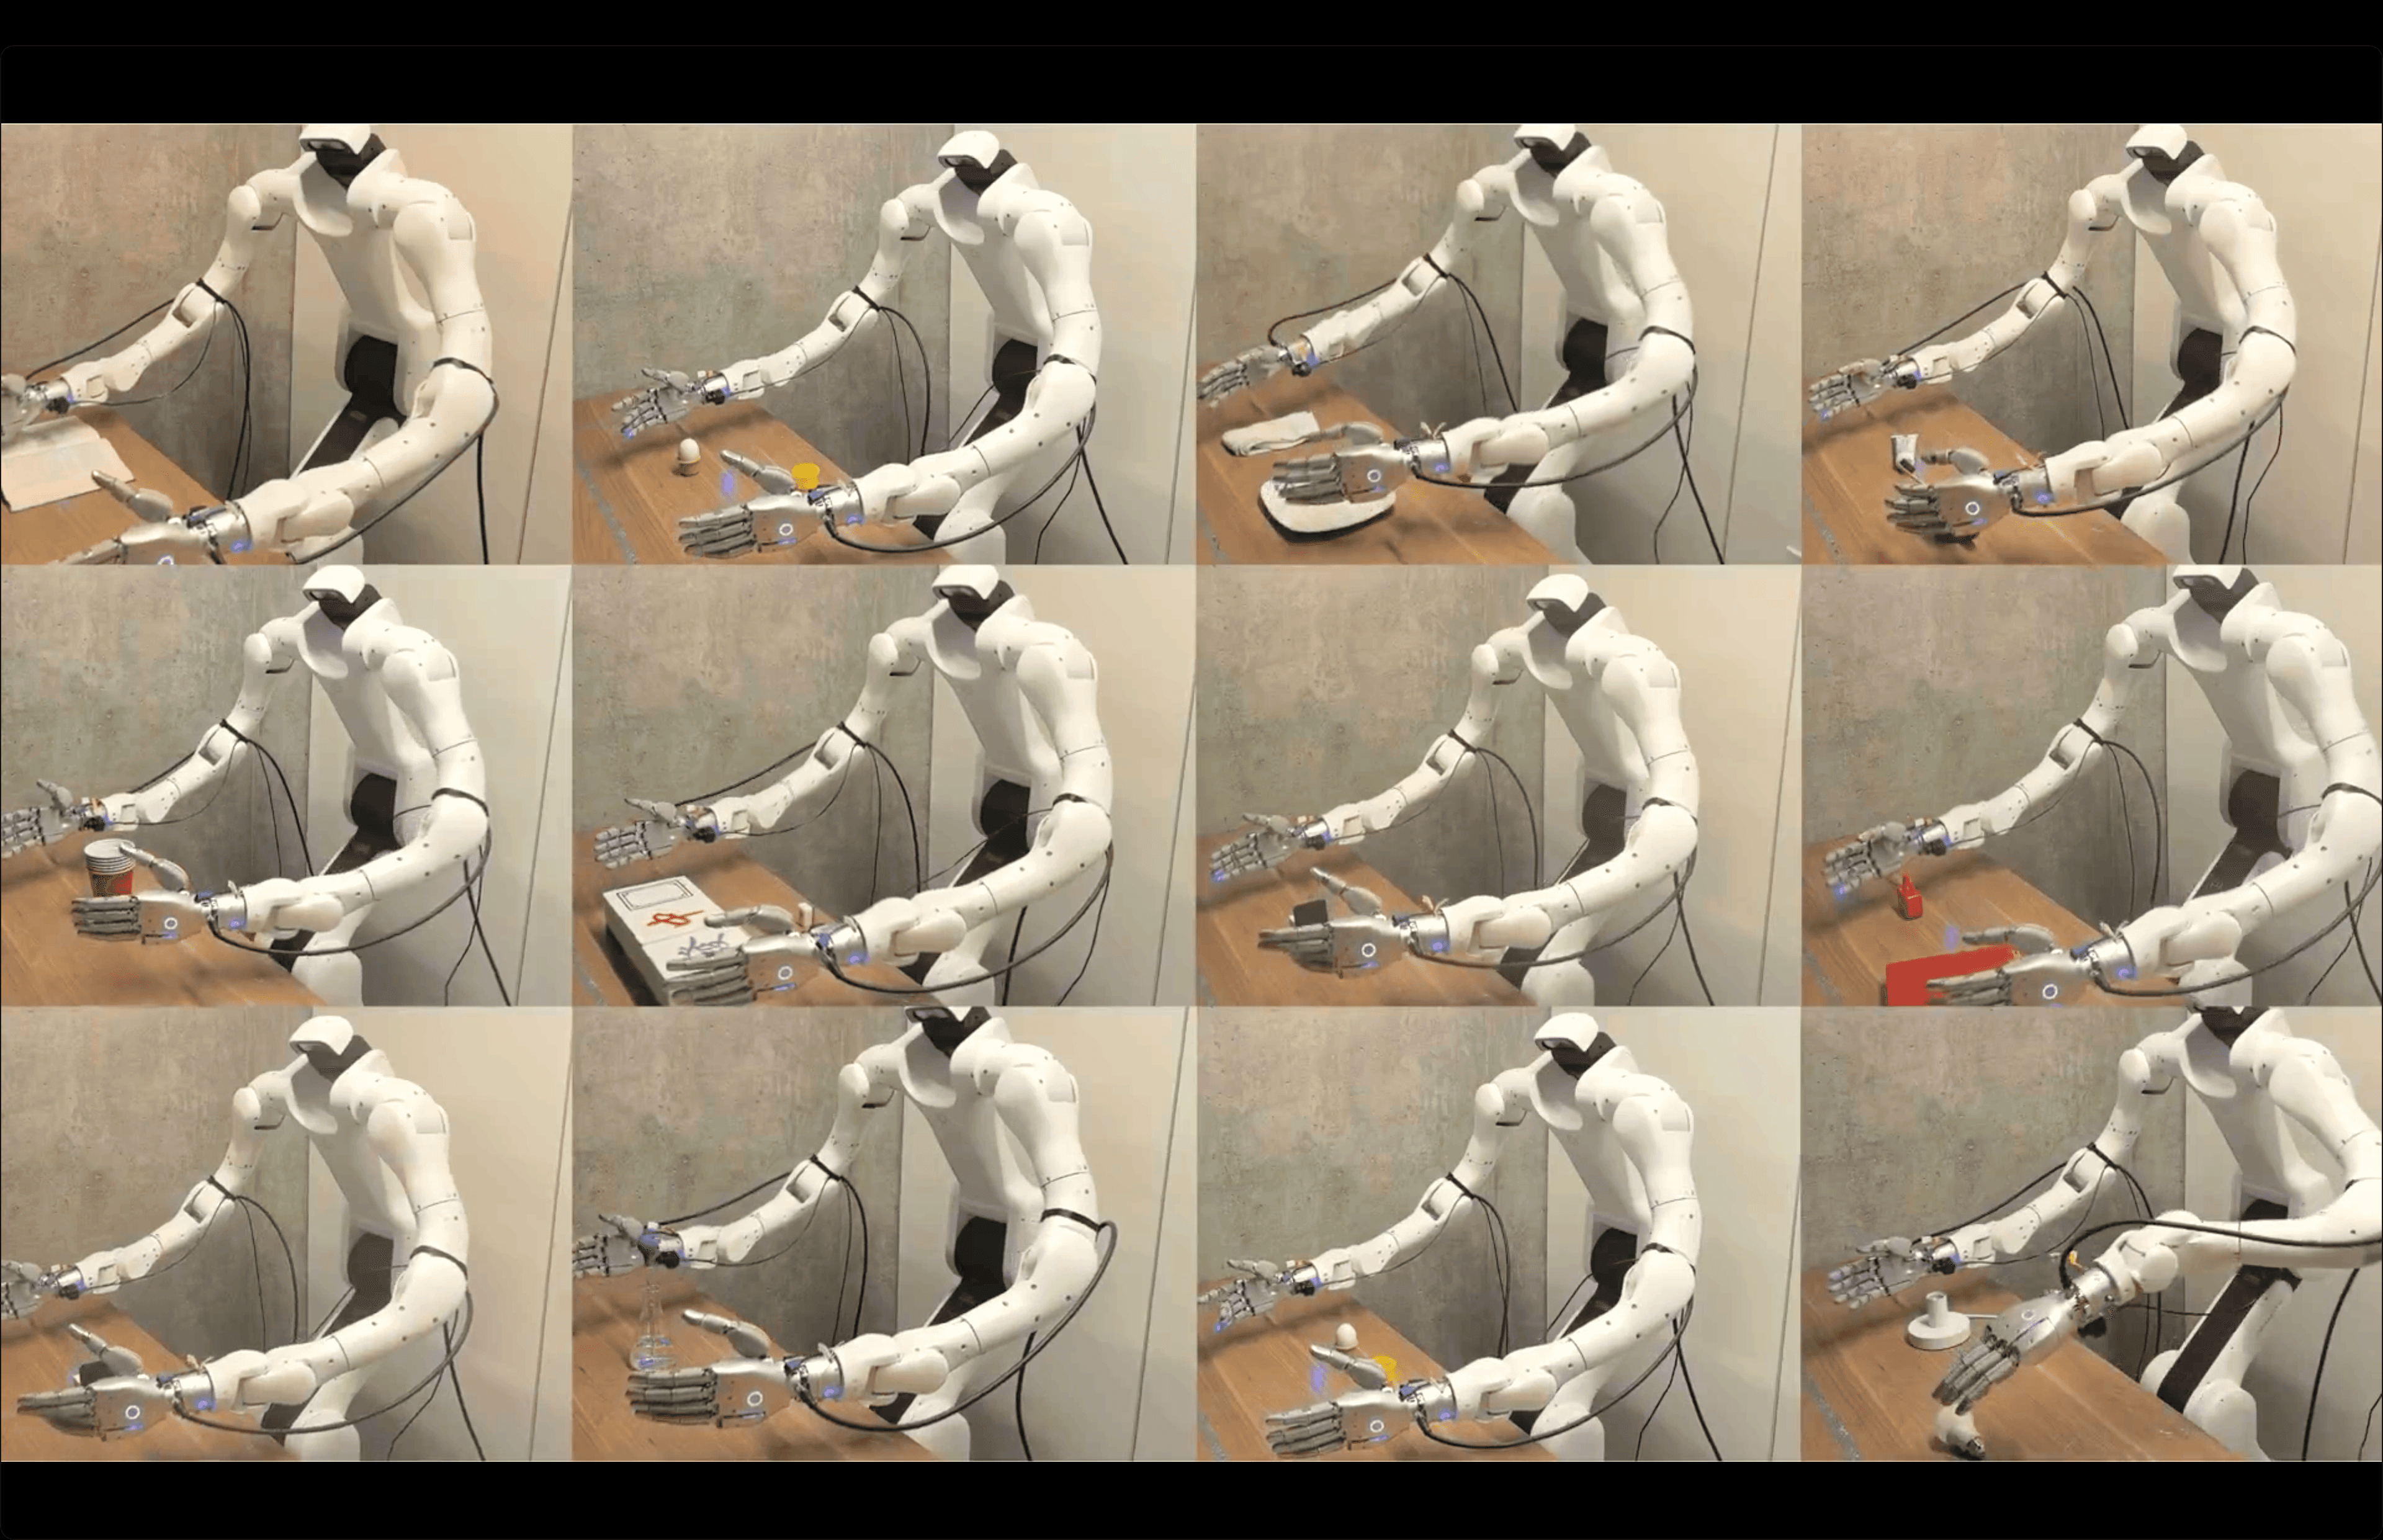
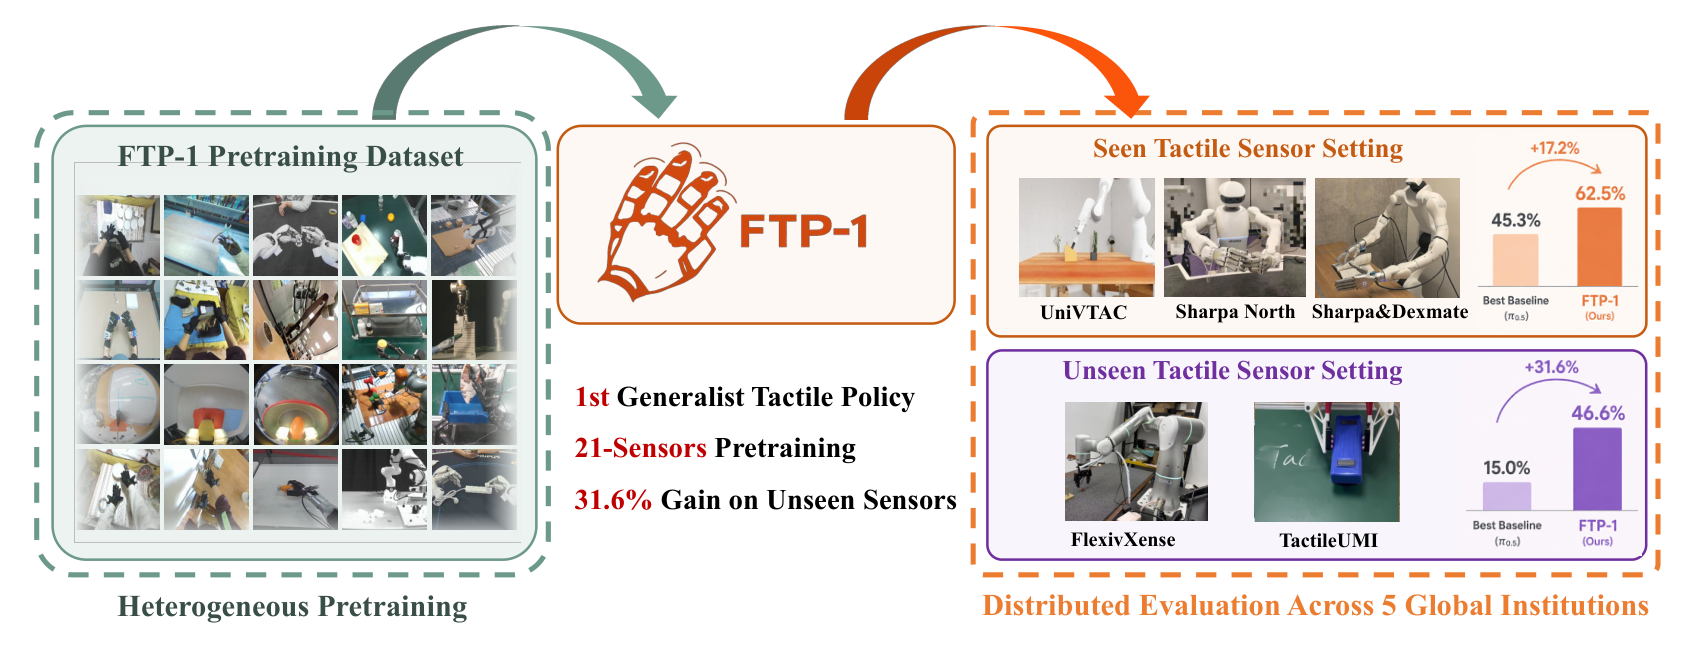
Stanford, Michigan and Microsoft Research pretrain a force-aware robot foundation model on human tactile data plus 100 hours of robot demonstrations. That robot data is the T-Rex corpus, collected on a Dexmate Vega with Sharpa Wave hands.