DUET: Dual-Robot Understanding via Efficient Teaching
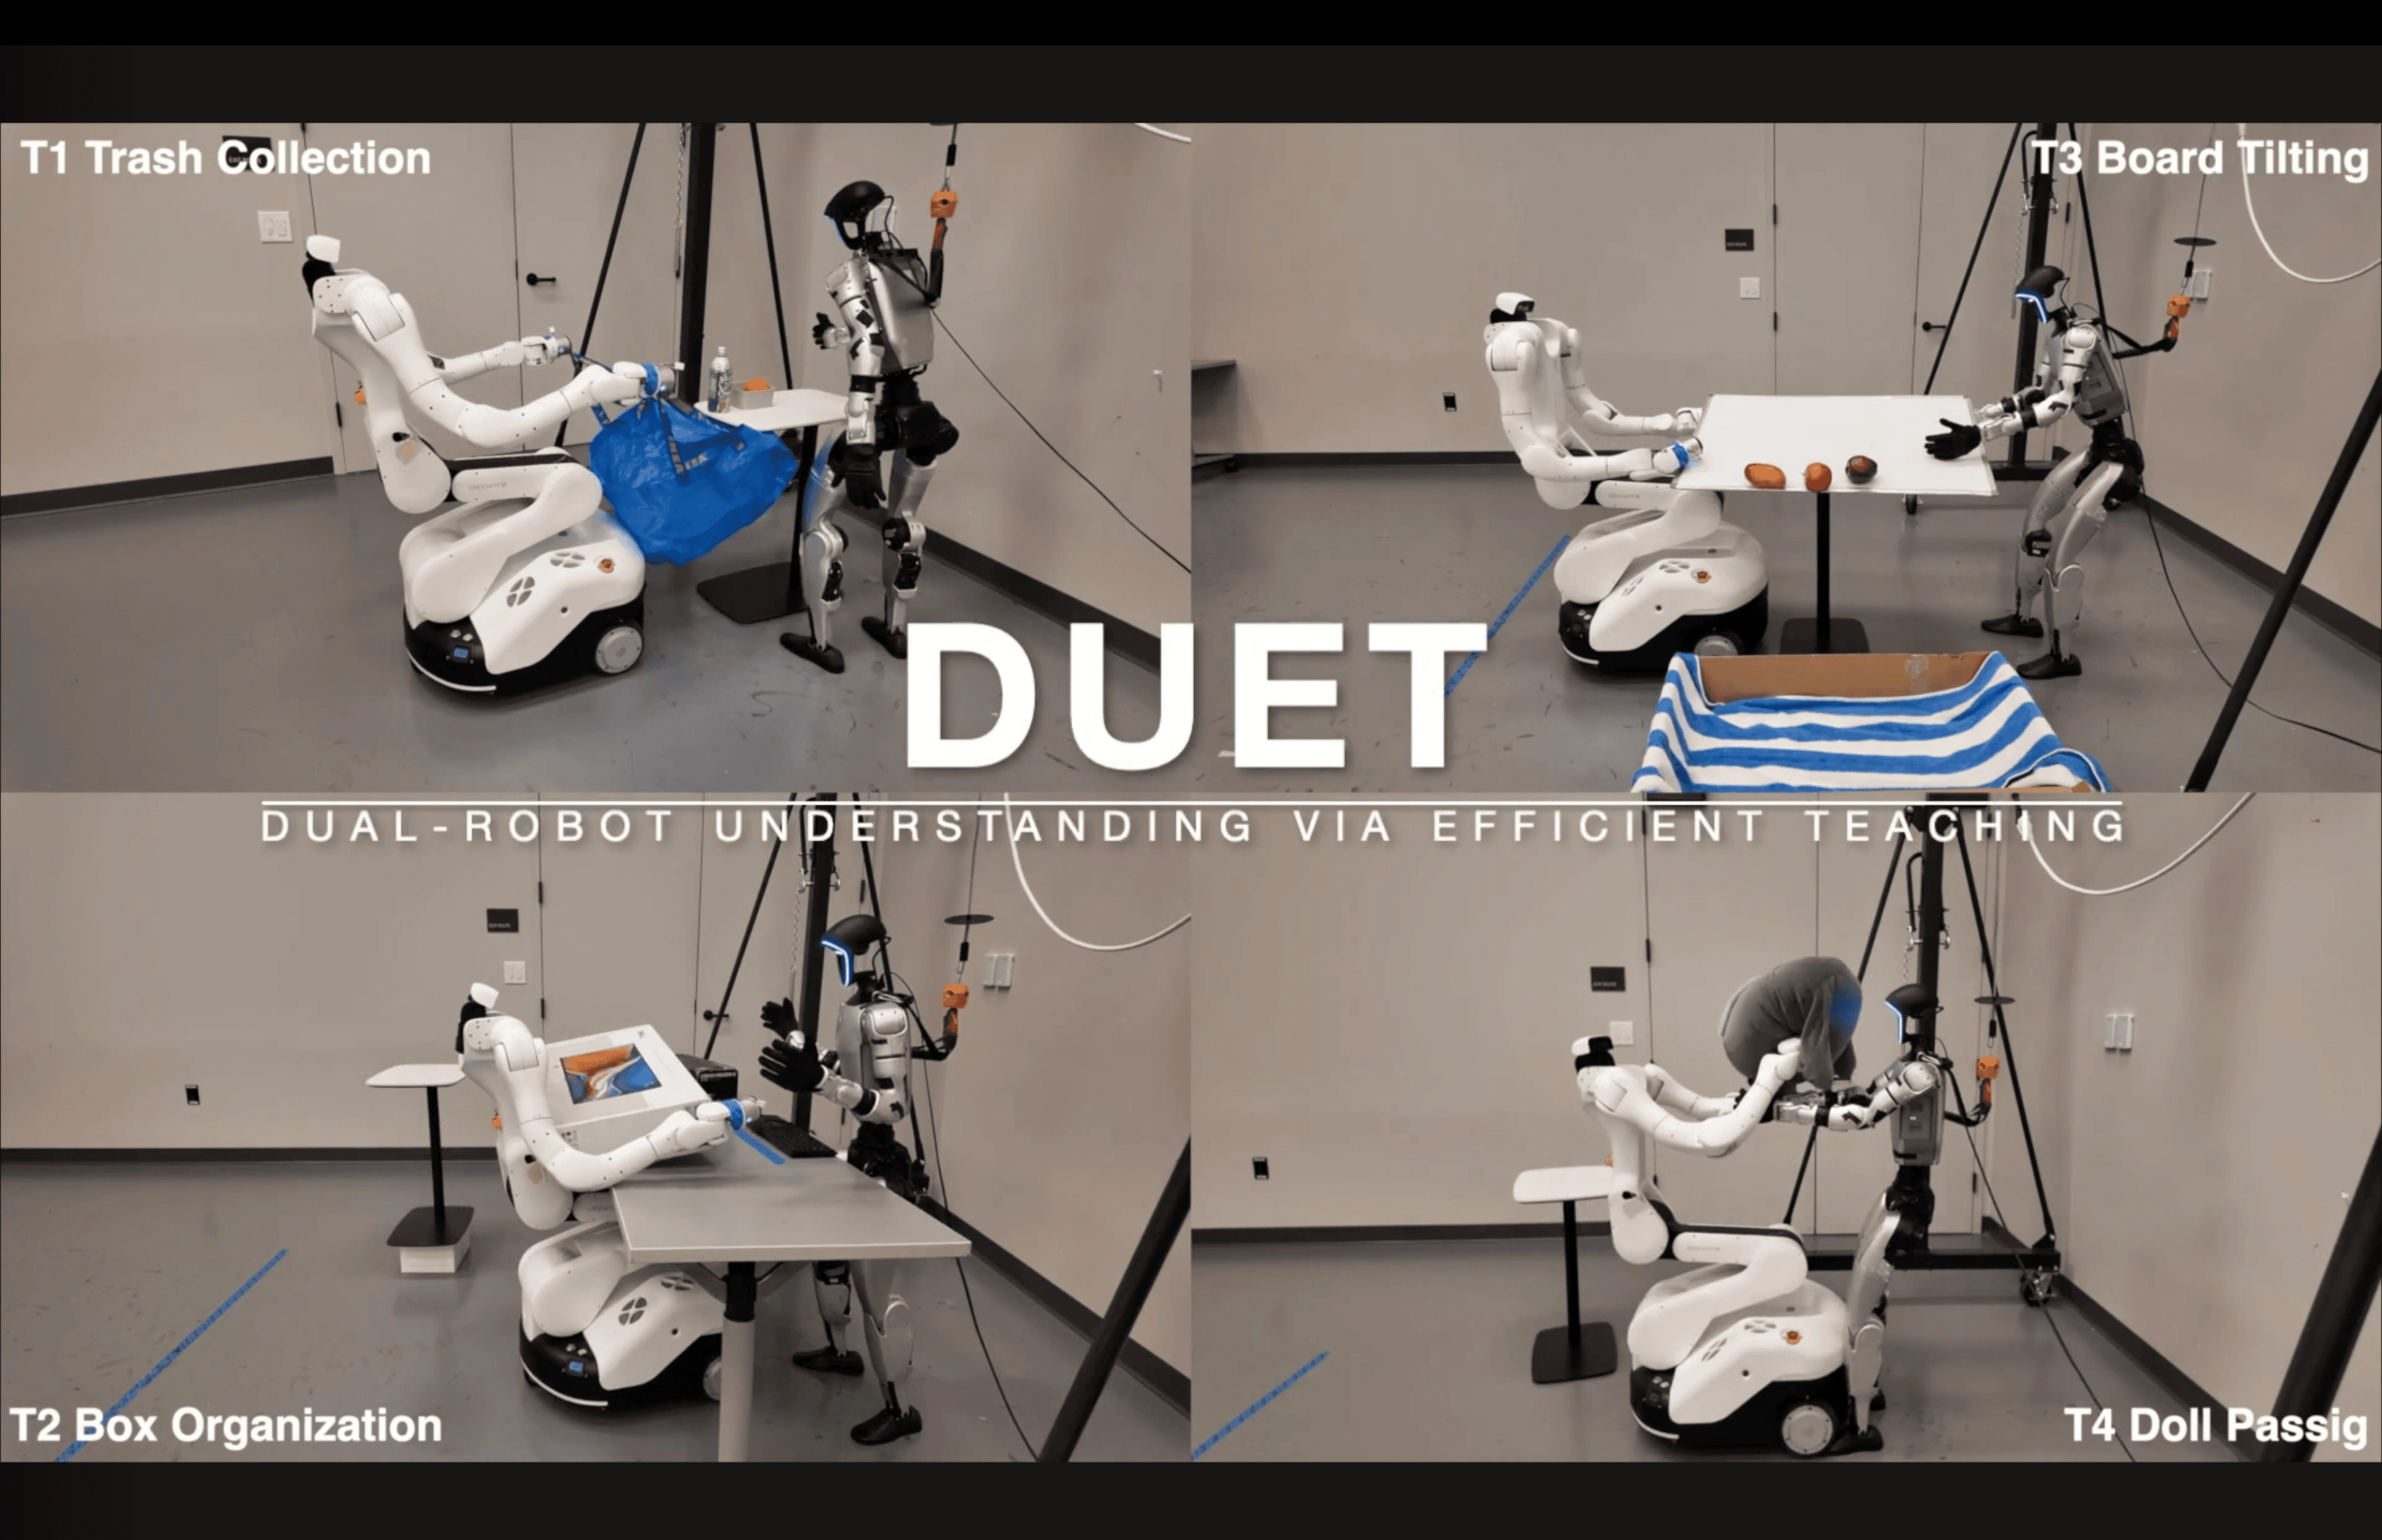
USC, Toyota Research Institute and Stanford teach a Dexmate Vega and a Unitree G1 to work as a pair, learning from people who teleoperate both robots at once across four two-robot tasks.
Duet: Dual-Robot Understanding via Efficient Teaching
- 1University of Southern California
- 2Toyota Research Institute
- 3Stanford University
* Equal contribution
arXiv preprint arXiv:2606.20990
Abstract
Dual-robot collaboration enables tasks that exceed the reach and payload of a single robot, such as collaboratively transporting objects across environments and executing coordinated handovers. Data acquisition is the primary bottleneck for training these systems. To this end, we introduce DUET, a dual-robot learning framework for mobile manipulation. For efficient data collection, we create a unified dual-embodiment synchronized VR-based teleoperation system for in-domain heterogeneous robot data collection. We further develop a complementary tracking pipeline that records human-human coordination and collaborative mobile manipulation priors. To allow efficient learning, we introduce an Action Chunking Transformer based architecture that first pretrains collaborative policies on efficient human-human demonstrations, before finetuning them on a minimal set of real-robot teleoperation trajectories. We develop a benchmark of four collaborative tasks to evaluate our framework using a Unitree G1 humanoid and a Dexmate Vega1 mobile manipulator. The results demonstrate that harnessing human priors not only yields superior task performance compared to baselines trained only on robot data, but also reduces the total human effort required for data collection. Our human data collection pipeline achieves 5.4 times acceleration on average from teleoperation, but we perform better than robot-only data trained policies across all tasks. Our project page is available at https://zhaoy37.github.io/Duet/.
Citation
@misc{zhao2026duetdualrobotunderstandingefficient, title = {Duet: Dual-Robot Understanding via Efficient Teaching}, author = {Yiqi Zhao and Ruohai Ge and Celina Shiyu Wang and Junjie Ye and Muchen Xu and Minhao Li and Sergey Zakharov and Basile Van Hoorick and Vitor Campagnolo Guizilini and Leonidas Guibas and Gaurav S. Sukhatme and Jyotirmoy V. Deshmukh and Yue Wang}, year = {2026}, eprint = {2606.20990}, archivePrefix = {arXiv}, primaryClass = {cs.RO}, url = {https://arxiv.org/abs/2606.20990},}Platform
DUET pairs a Dexmate Vega 1 Pro with a Unitree G1 humanoid. Two operators teleoperate the robots together through VR headsets, and the four benchmark tasks, trash collection, box organization, board tilting and doll passing, all need both robots at once. Vega is available today as Vega 1 Pro and Vega 1 U. See all research published on Dexmate robots.
Related Research
Start Your Physical AI Journey with Us