UC Berkeley, NVIDIA, Sapienza University of Rome
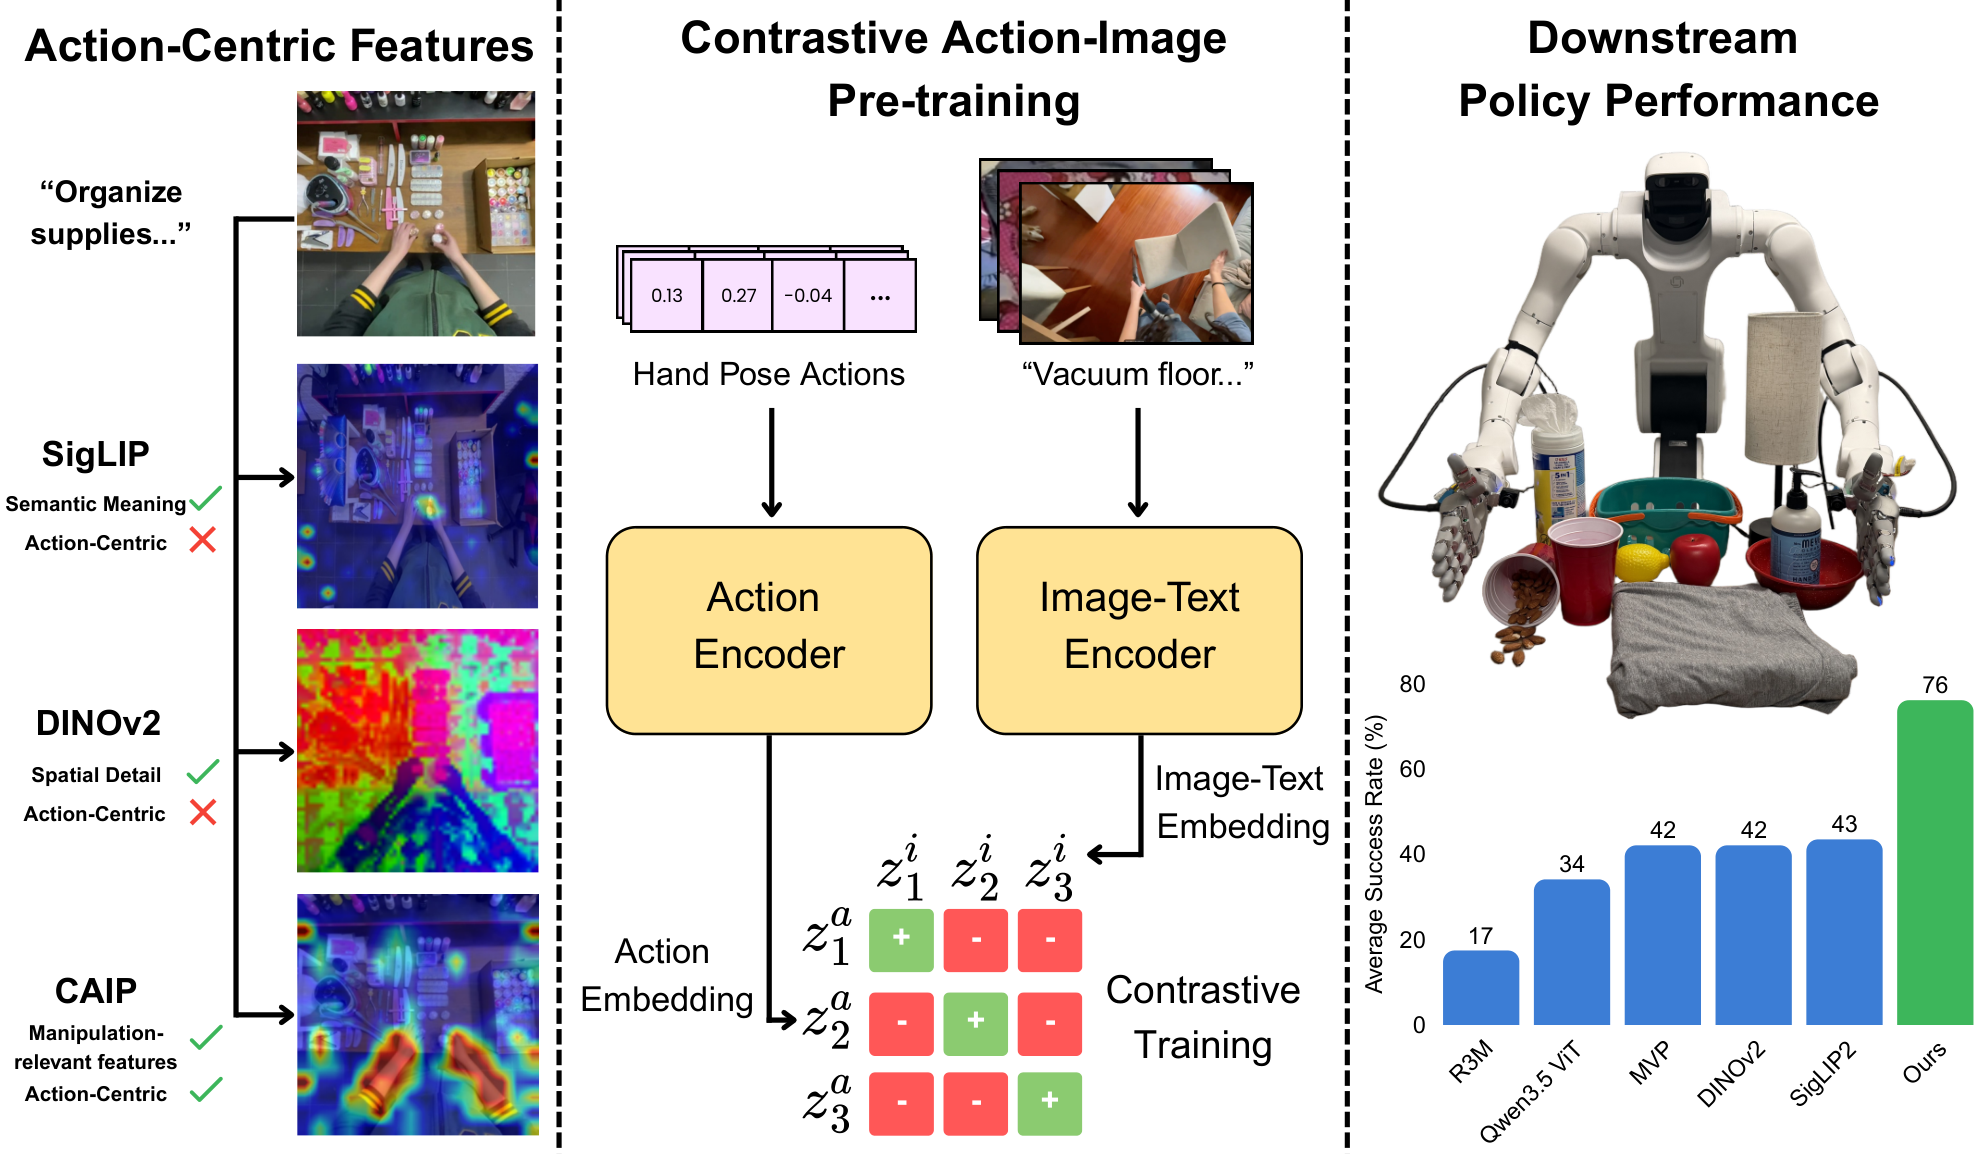
CAIP: Contrastive Action-Image Pre-training for Visuomotor Control
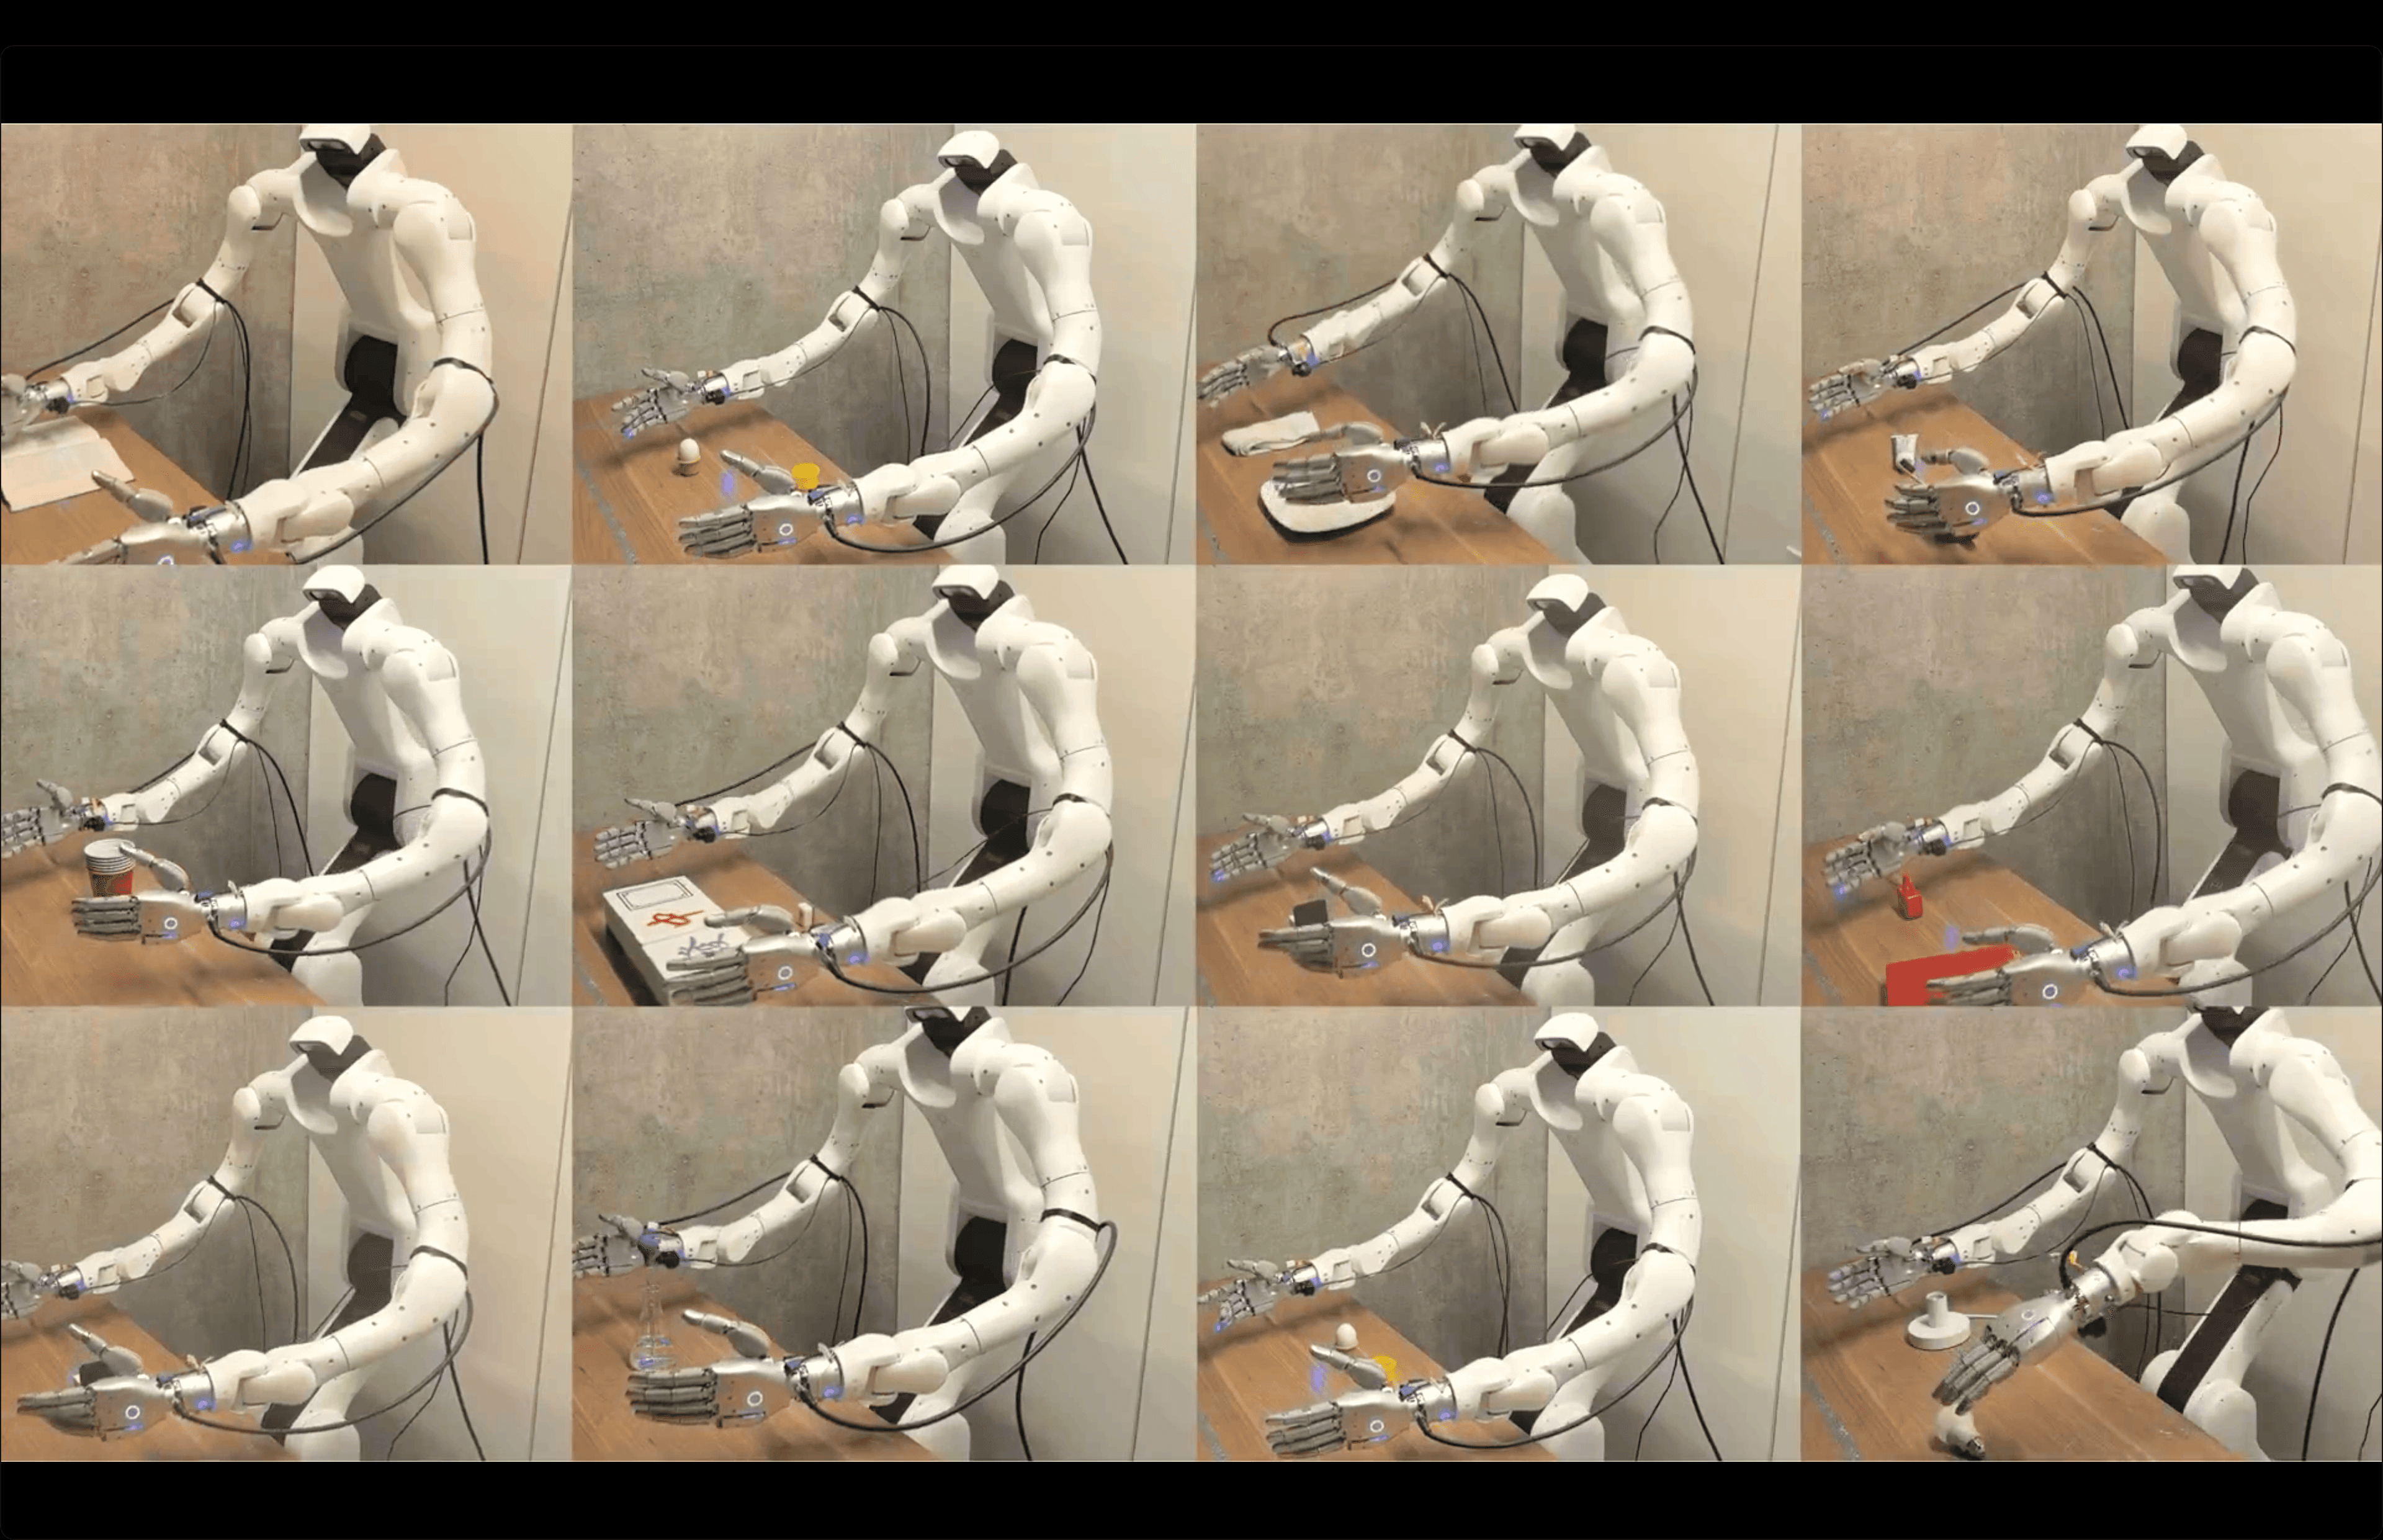
A vision encoder pre-trained on 3D hand keypoints from 32,041 hours of human video lifts real-world dexterous success on a Dexmate Vega with Sharpa Wave hands by more than 30 points over the strongest baseline.
Learn MoreUC Berkeley, UIUC, Northwestern University
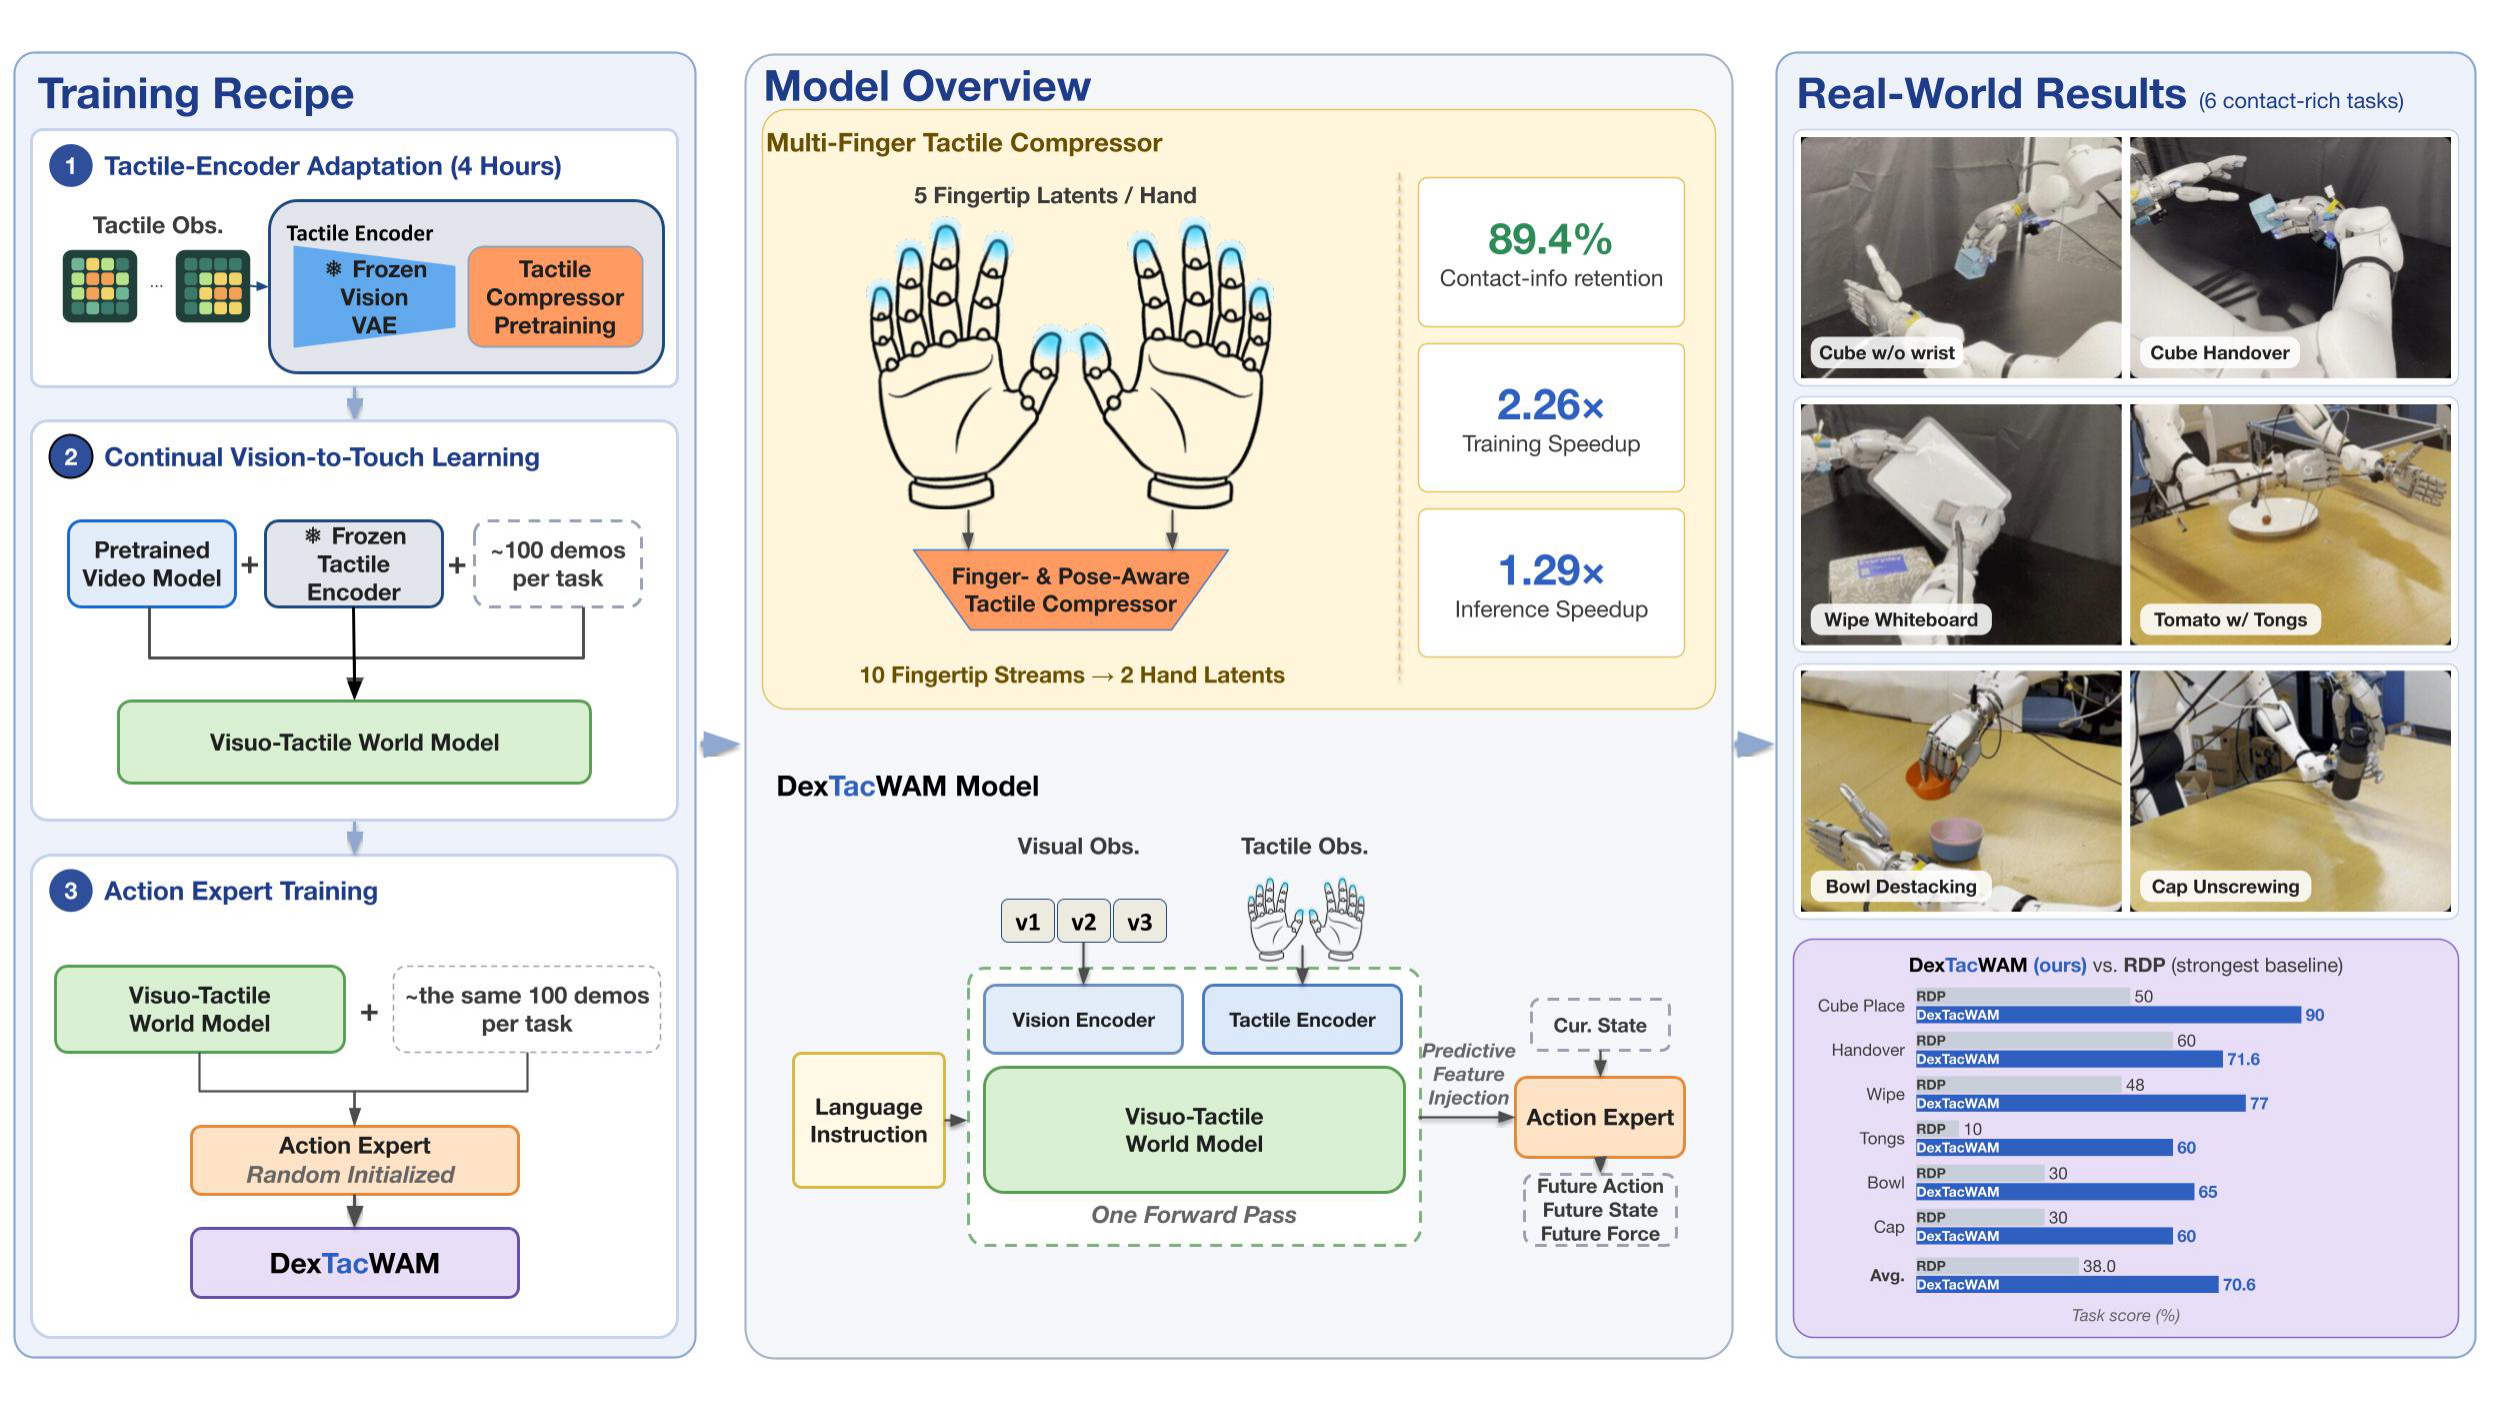
DexTacWAM: Touch-Aware World Models for Dexterous Manipulation
A video world model learns to predict touch on Dexmate's Vega, raising success on six contact-rich dexterous tasks to 70.6 against 38.0 for the strongest baseline.
Learn MoreDexmate, Carnegie Mellon University, Purdue University
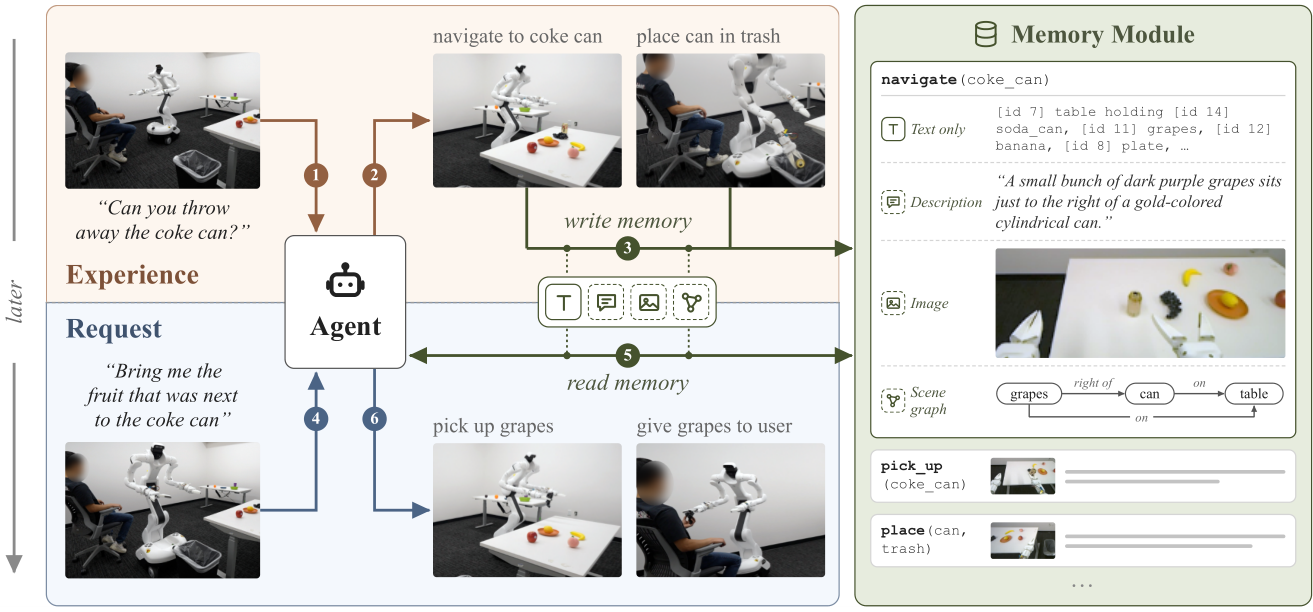
MeMoREval: What Should Embodied Agents Remember?
A benchmark for which memory modality an embodied agent should keep, with reference evaluations across four simulated environments and a demonstration on a physical Vega 1.
Learn MoreUC Berkeley, NVIDIA, Stanford
T-Rex: Tactile-Reactive Dexterous Manipulation
Giving robots a sense of touch boosts success on delicate two-handed manipulation tasks, run on a Dexmate Vega with dexterous hands.
Learn More