ReVeal: A Reconstruction-Aware Real-to-Sim Framework for VLA Policy Evaluation
Purdue and Samsung SDS Research America build a real-to-sim pipeline for evaluating vision-language-action policies, then check how well the simulation predicts the real robot. Every experiment, simulated and physical, runs on a Dexmate Vega.
- 1Purdue University
- 2Samsung SDS Research America
arXiv preprint arXiv:2609.23910
Abstract
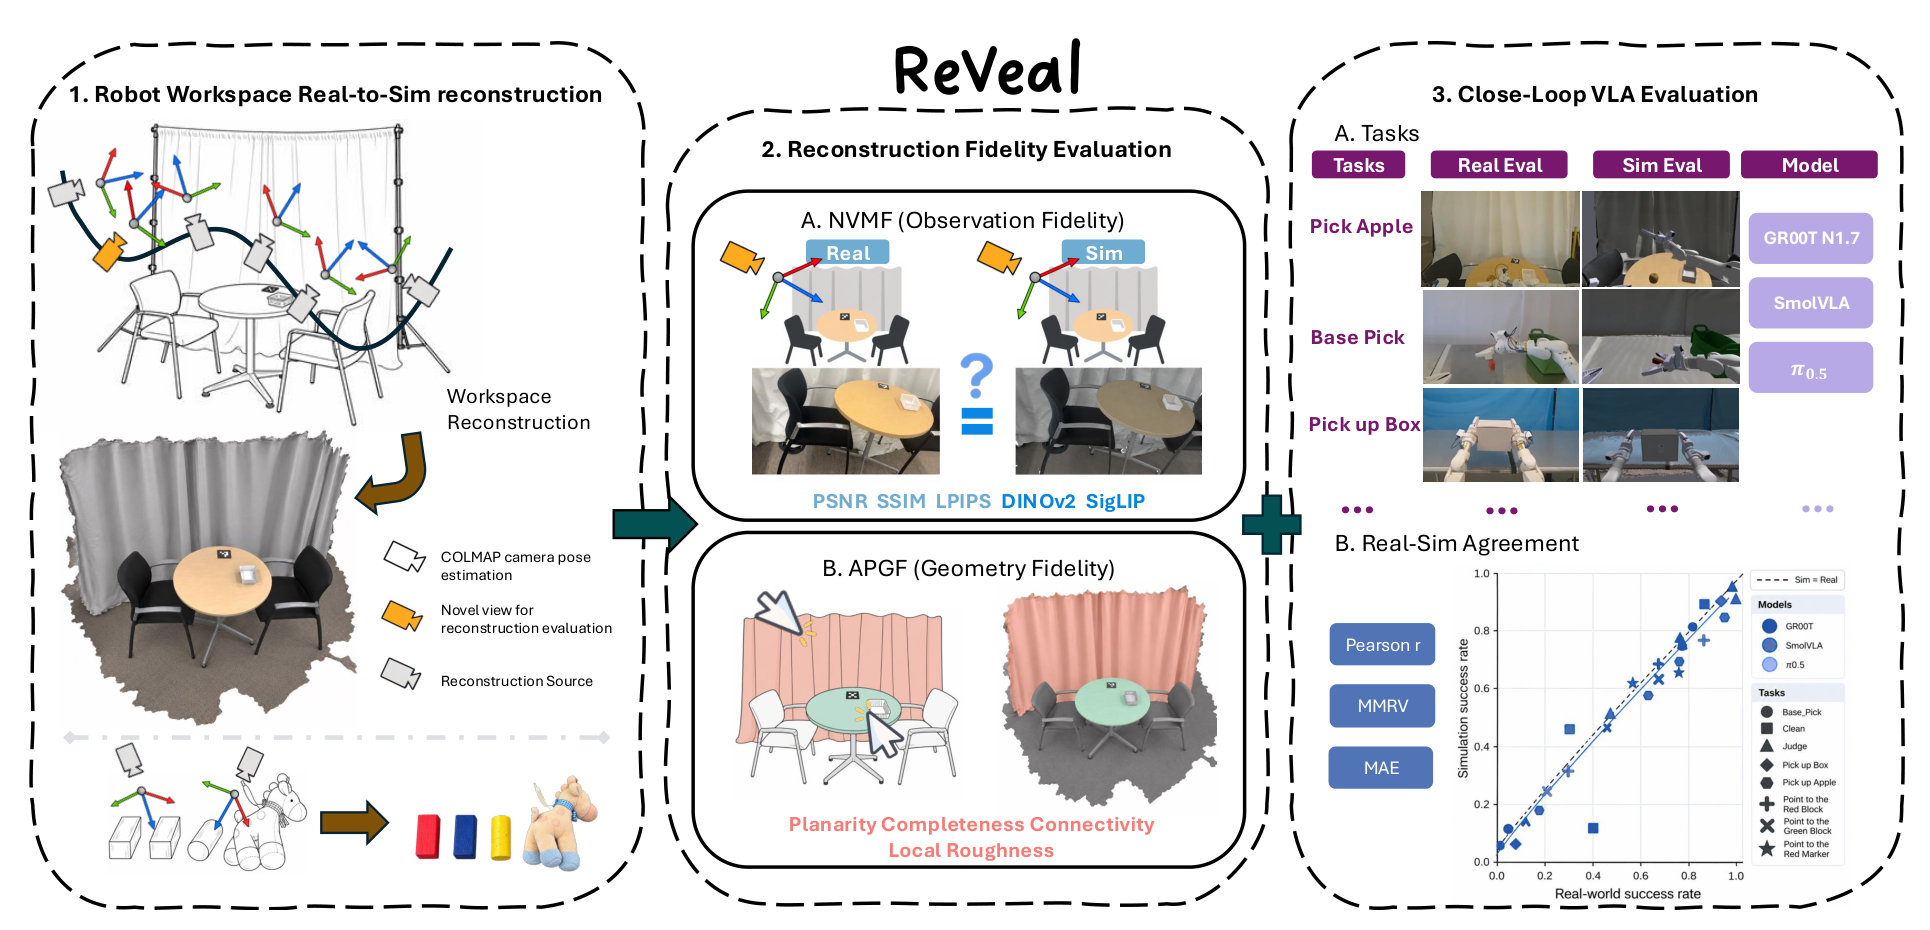
Simulation-based evaluation provides a scalable and repeatable alternative to real-world evaluation of vision-language-action (VLA) policies. However, reconstruction errors can cause simulated policy performance to diverge from real-world performance, motivating the need to assess reconstructed environments for downstream VLA policy evaluation. We present ReVeal, a real-to-sim assessment framework combining workspace reconstruction, reconstruction-level assessment, and matched closed-loop policy evaluation. Novel-View Mesh Fidelity (NVMF) and Annotated Planar Geometry Fidelity (APGF) assess observation and planar geometric fidelity, respectively. We also develop PGSR-D, a reconstruction pipeline incorporating monocular depth supervision to improve geometry where multi-view visual cues are limited. Across 8 assessment scenes, NVMF and APGF consistently distinguish the fidelity of 2DGS, PGSR, and PGSR-D. Matched evaluations of GR00T, SmolVLA, and pi0.5 across 8 humanoid manipulation tasks show consistent ordering between reconstruction fidelity and real-sim performance agreement across pipelines. Further analysis of the evaluation workspaces shows that higher fidelity is associated with stronger real-sim agreement.
Citation
@misc{wang2026revealreconstructionawarerealtosimframework, title = {ReVeal: A Reconstruction-Aware Real-to-Sim Framework for VLA Policy Evaluation}, author = {Xinyi Wang and Heng Hao and Wenjun Hu and Anna Enyu Li and Dizhi Ma and Karthik Ramani and Hankyu Moon and Yeong-Dae Kwon}, year = {2026}, eprint = {2609.23910}, archivePrefix = {arXiv}, primaryClass = {cs.RO}, url = {https://arxiv.org/abs/2609.23910}, }Start Your Physical AI Journey with Us