FTP-1: A Generalist Foundation Tactile Policy Across Tactile Sensors for Contact-Rich Manipulation
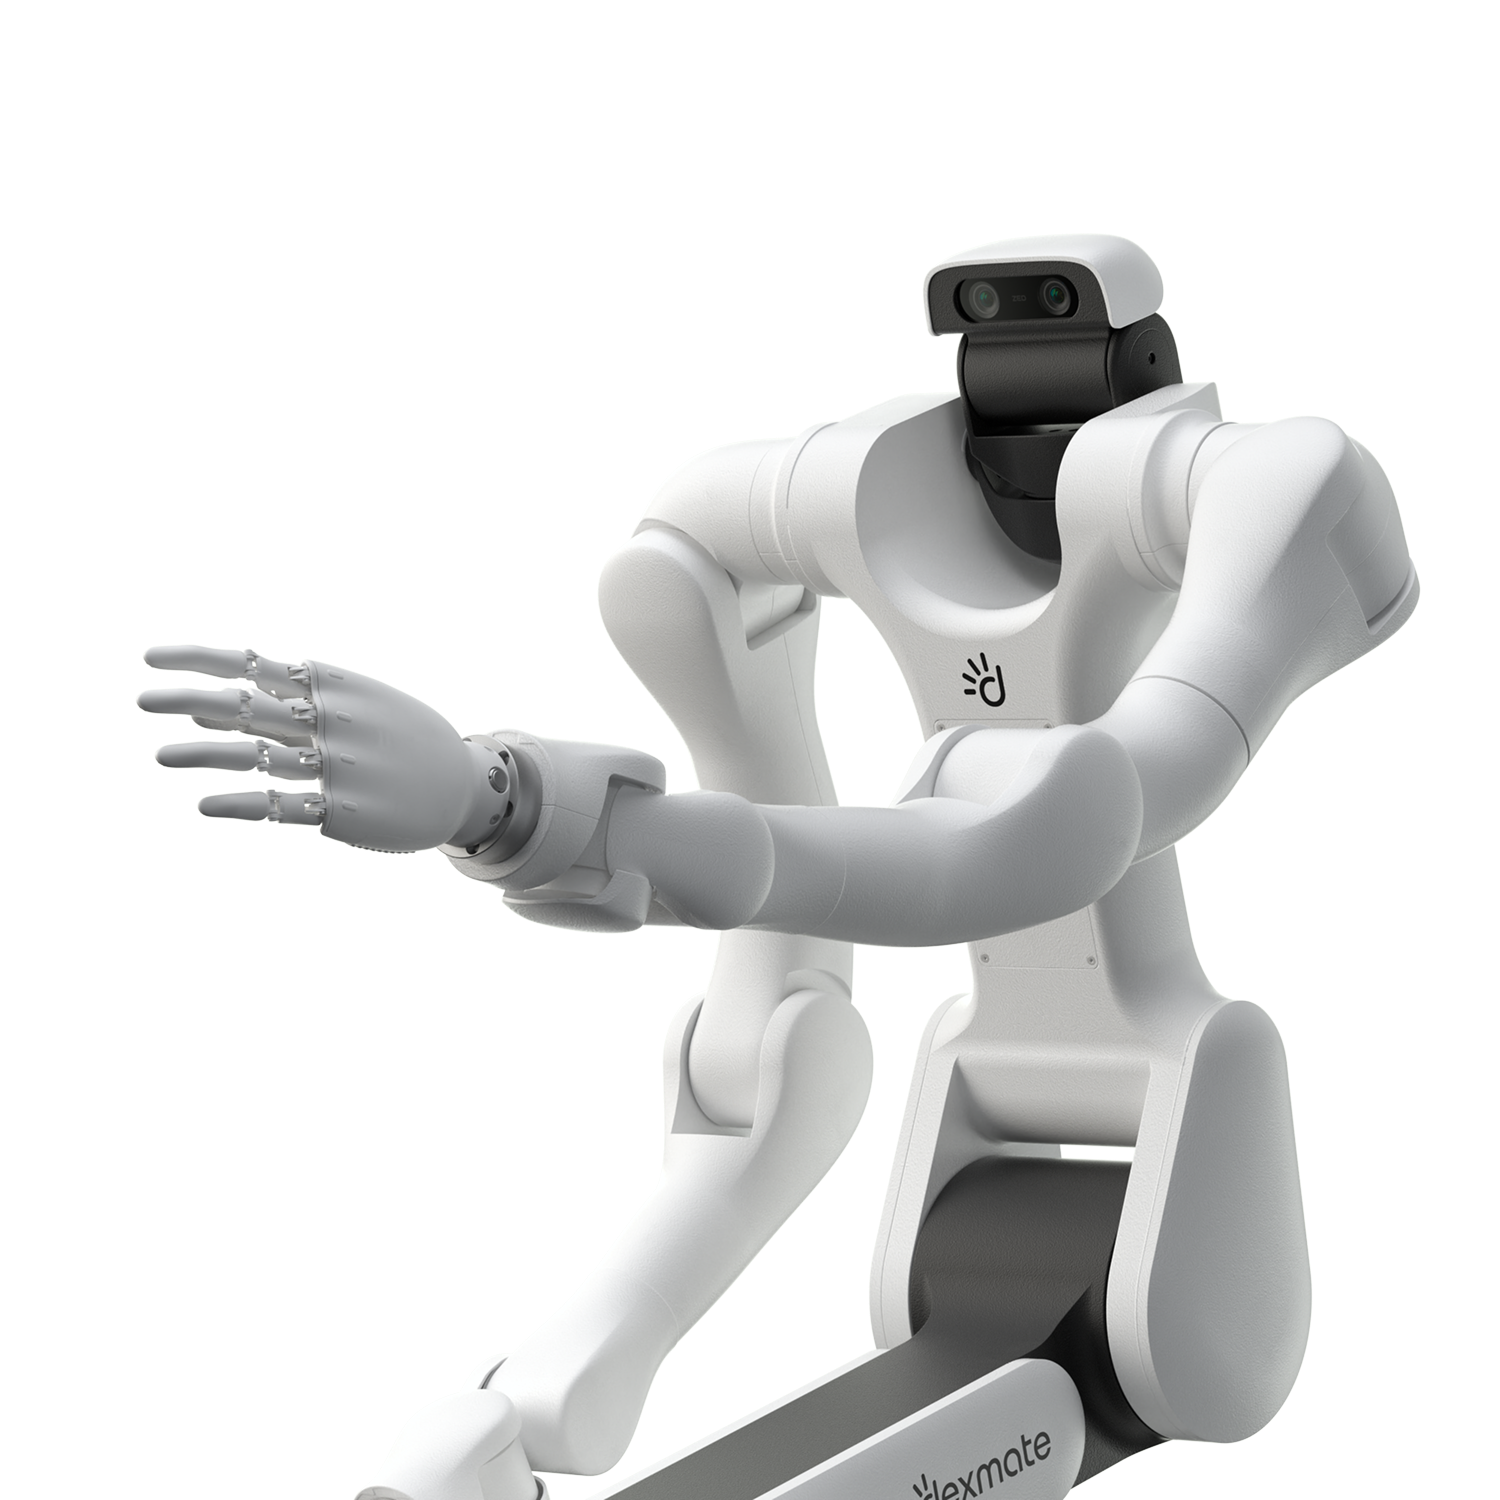
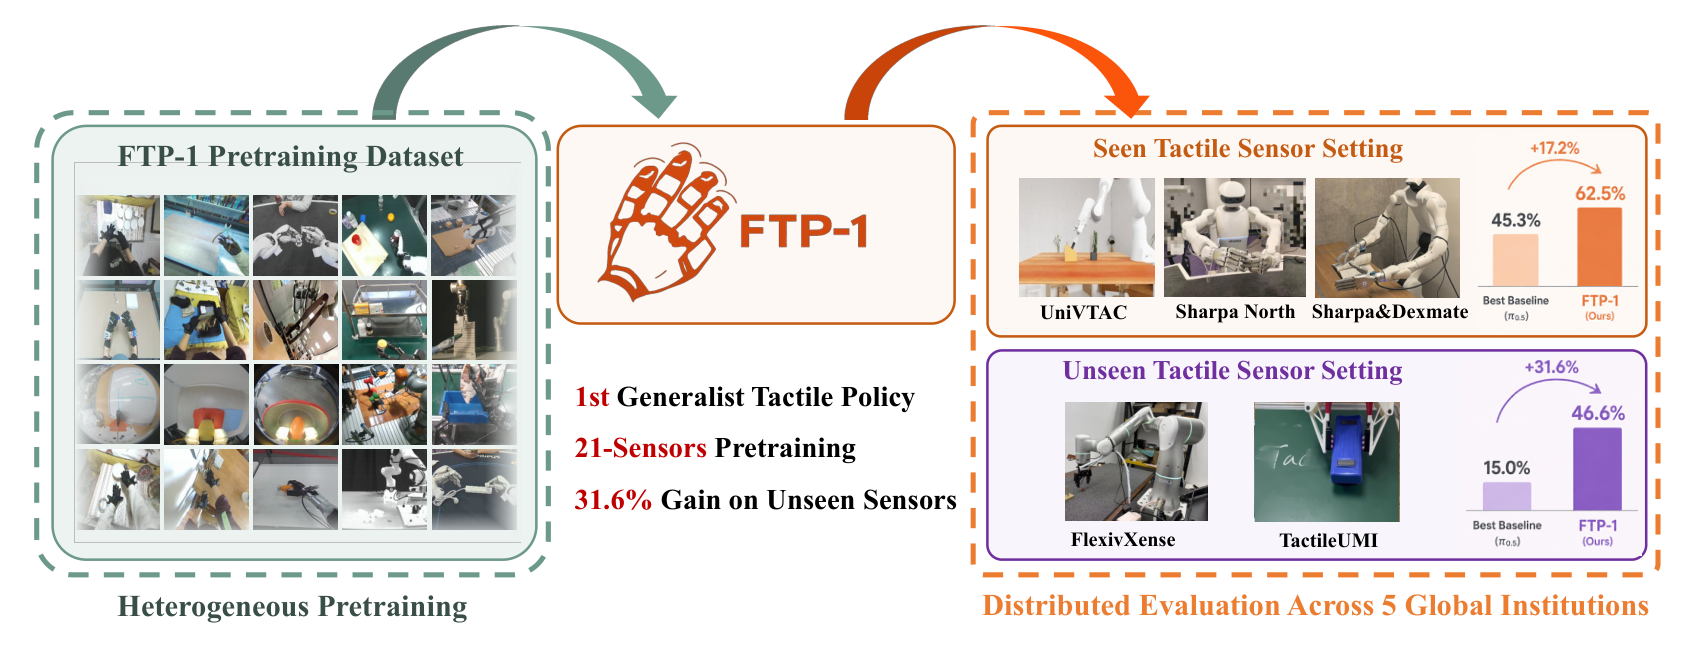
A tactile foundation policy from Tsinghua, Sharpa and partners, pretrained on about 3,000 hours of touch data across 21 sensors. One of its three real-world test rigs is a Dexmate Vega with Sharpa Wave hands, a robot the model had never seen in pretraining.
- 1Tsinghua University
- 2Shanghai Qi Zhi Institute
- 3Sharpa
- 4Shanghai Jiao Tong University
- 5University of California, Berkeley
- 6ETH Zurich
- 7Fudan University
- 8Shanghai Innovation Institute
* Equal contribution · ‡ Project leader · † Corresponding author
arXiv preprint arXiv:2606.13102
Abstract
Despite the success of vision-based generalist robotic policies, existing tactile-based policies remain tied to fixed embodiments and sensor setups. This is because tactile signals are highly heterogeneous across hardware, making cross-sensor generalization difficult. We present FTP-1,the first generalist foundation tactile policy pretrained to acquire transferable tactile manipulation abilities across diverse sensors and embodiments. FTP-1 supports varied tactile inputs, including image-, array-, and state-based signals, by using heterogeneous encoders to project them into unified morphology-aware latent tokens that are jointly modeled by a shared tactile Transformer expert. Pretrained on around 3,000 hours of tactile manipulation data aggregated from 26 data sources, spanning human and robot demonstrations across 21 sensors, FTP-1 learns tactile skills that transfer beyond the sensors seen during pretraining. Across downstream finetuning experiments spanning 5 hardware configurations, FTP-1 improves contact-rich manipulation on seen sensor setups by +17.2% and, surprisingly, transfers to two previously unseen tactile-sensor setups, achieving a +31% gain in success rate. FTP-1 establishes the first unified foundation baseline for tactile manipulation, providing future tactile policies with a shared model-level starting point. Pretrained models, datasets, training code and more visualization at https://ftp1-policy.github.io.
Citation
@misc{yuan2026ftp1generalistfoundationtactile, title = {FTP-1: A Generalist Foundation Tactile Policy Across Tactile Sensors for Contact-Rich Manipulation}, author = {Chengbo Yuan and Zicheng Zhang and Mingjie Zhou and Wendi Chen and Yi Wang and Zhuoyang Liu and Dantong Niu and Shuo Wang and Hui Zhang and Wenkang Zhang and Yingdong Hu and Yuanqing Gong and Wanli Xing and Chuan Wen and Cewu Lu and Kaifeng Zhang and Yang Gao}, year = {2026}, eprint = {2606.13102}, archivePrefix = {arXiv}, primaryClass = {cs.RO}, url = {https://arxiv.org/abs/2606.13102}, }Start Your Physical AI Journey with Us