Abstract
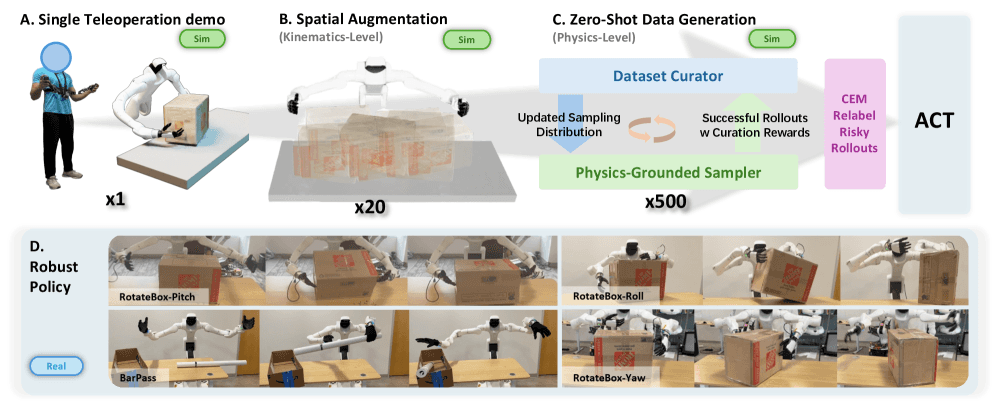
Behavior cloning for contact-rich bimanual manipulation remains challenging because diverse demonstrations are expensive to collect, and even small disturbances can push the system into off-manifold states where no recovery supervision is available. We propose PGDG, a data generation framework with zero-shot curation that expands a single demonstration into a compact dataset of physically plausible, successful, and diverse recovery behaviors without additional human labeling. PGDG iterates between a physics-grounded sampler and a dataset curator, where the curator selects informative, non-redundant, and recoverable behaviors to update the sampling distribution toward under-covered recovery modes, and the sampler draws physically plausible rollout candidates from this updated distribution and retains successful trajectories. To further improve data quality, PGDG applies short-horizon sampling-based control to relabel selected risky states with corrective actions. Across four bimanual manipulation tasks, PGDG consistently outperforms spatial-only augmentation in both simulation and zero-shot real-world transfer. On RotateBox-Pitch, success improves from 38% to 93% in simulation and from 35% to 82% in the real world. PGDG also enables effective foundation models fine-tuning such as GR00T, increasing success from 46% to 77%. Additional results are available in our website: https://cunxid.github.io/PGDG/.
Citation
@misc{dai2026pgdgphysicallygroundeddata,
      title={PGDG: Physically Grounded Data Generation for Robust Bimanual Policy Learning from a Single Demonstration},
      author={Cunxi Dai and Haoran Chang and Aditya Nisal and Rahul Kumar and Guofei Chen and Tao Chen and Yuzhe Qin and Guanya Shi},
      year={2026},
      eprint={2605.21710},
      archivePrefix={arXiv},
      primaryClass={cs.RO},
      url={https://arxiv.org/abs/2605.21710},
}